-
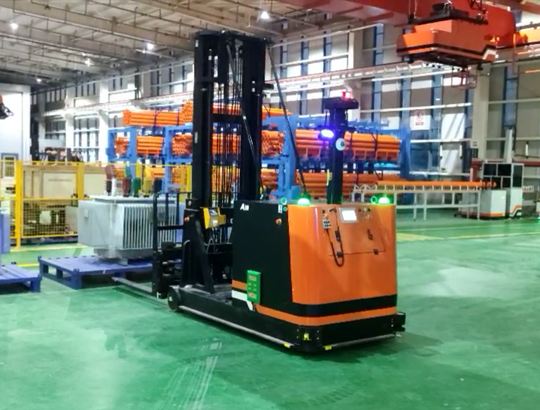 Forklift handling mobile robot
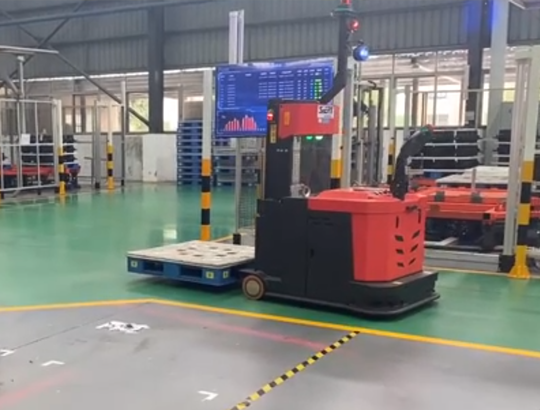 Reach mobile robots
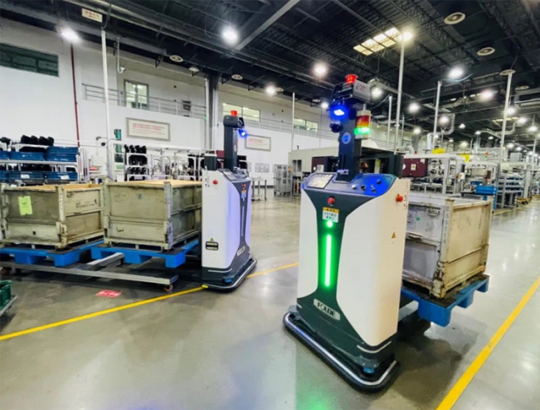 SLIM
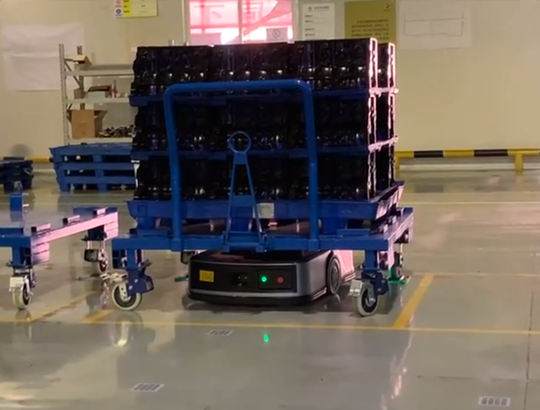 Jacking robot
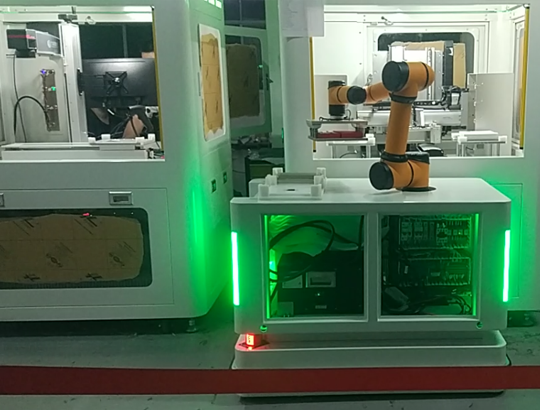 Cooperation robot
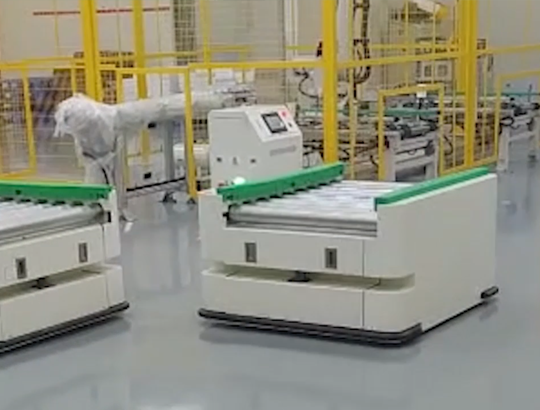 Roller mobile robot
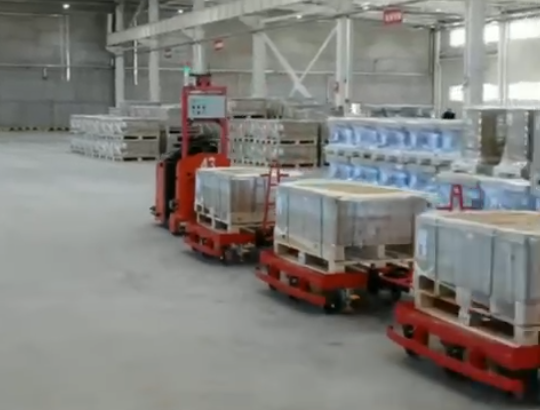 Towing mobile robot
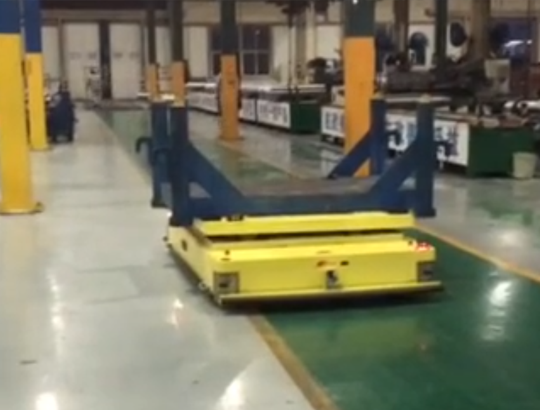 Platform handling robot
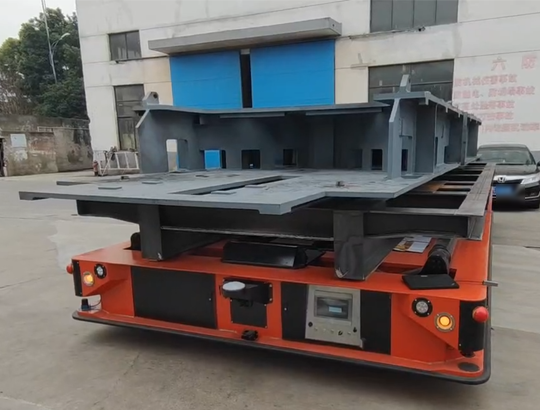 Heavy-load robot
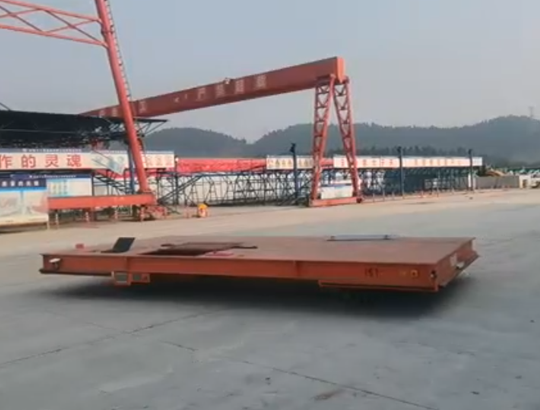 Outdoor loading mobile robot
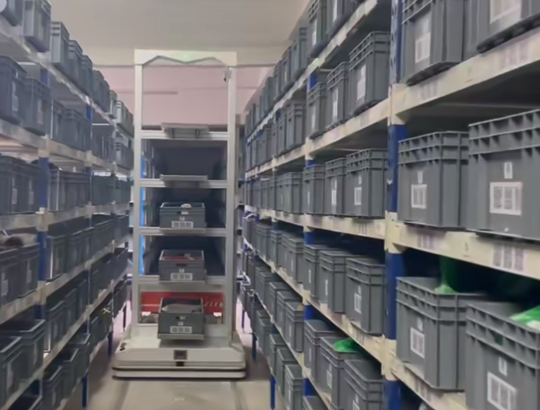 Pick robot
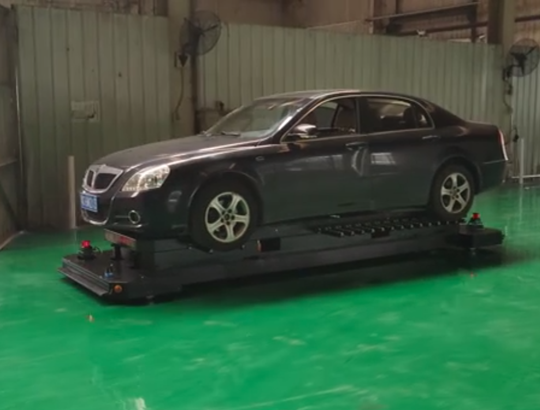 Parking robot
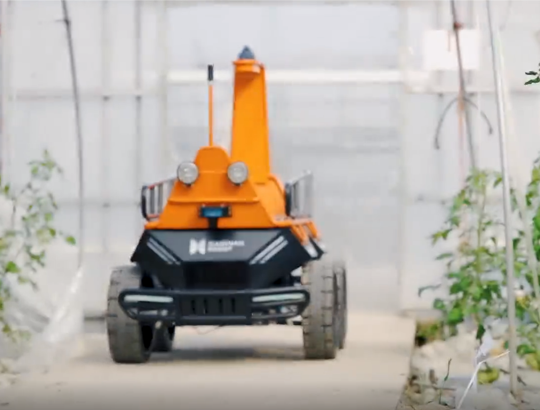 Agricultural robot
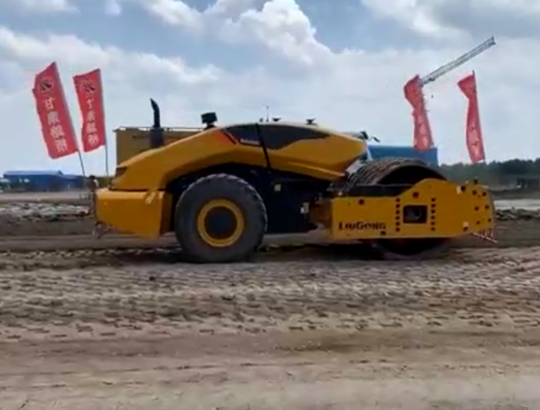 Driverless Road Roller robot
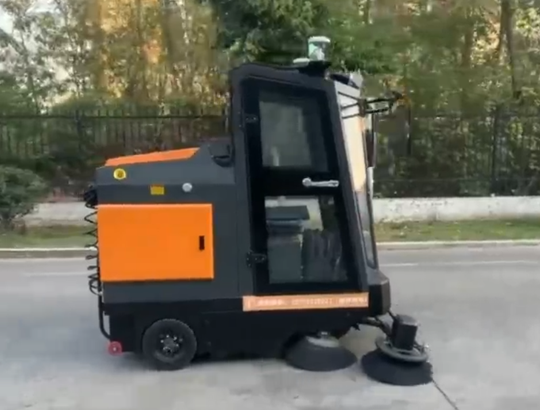 Driverless Sanitation vehicle

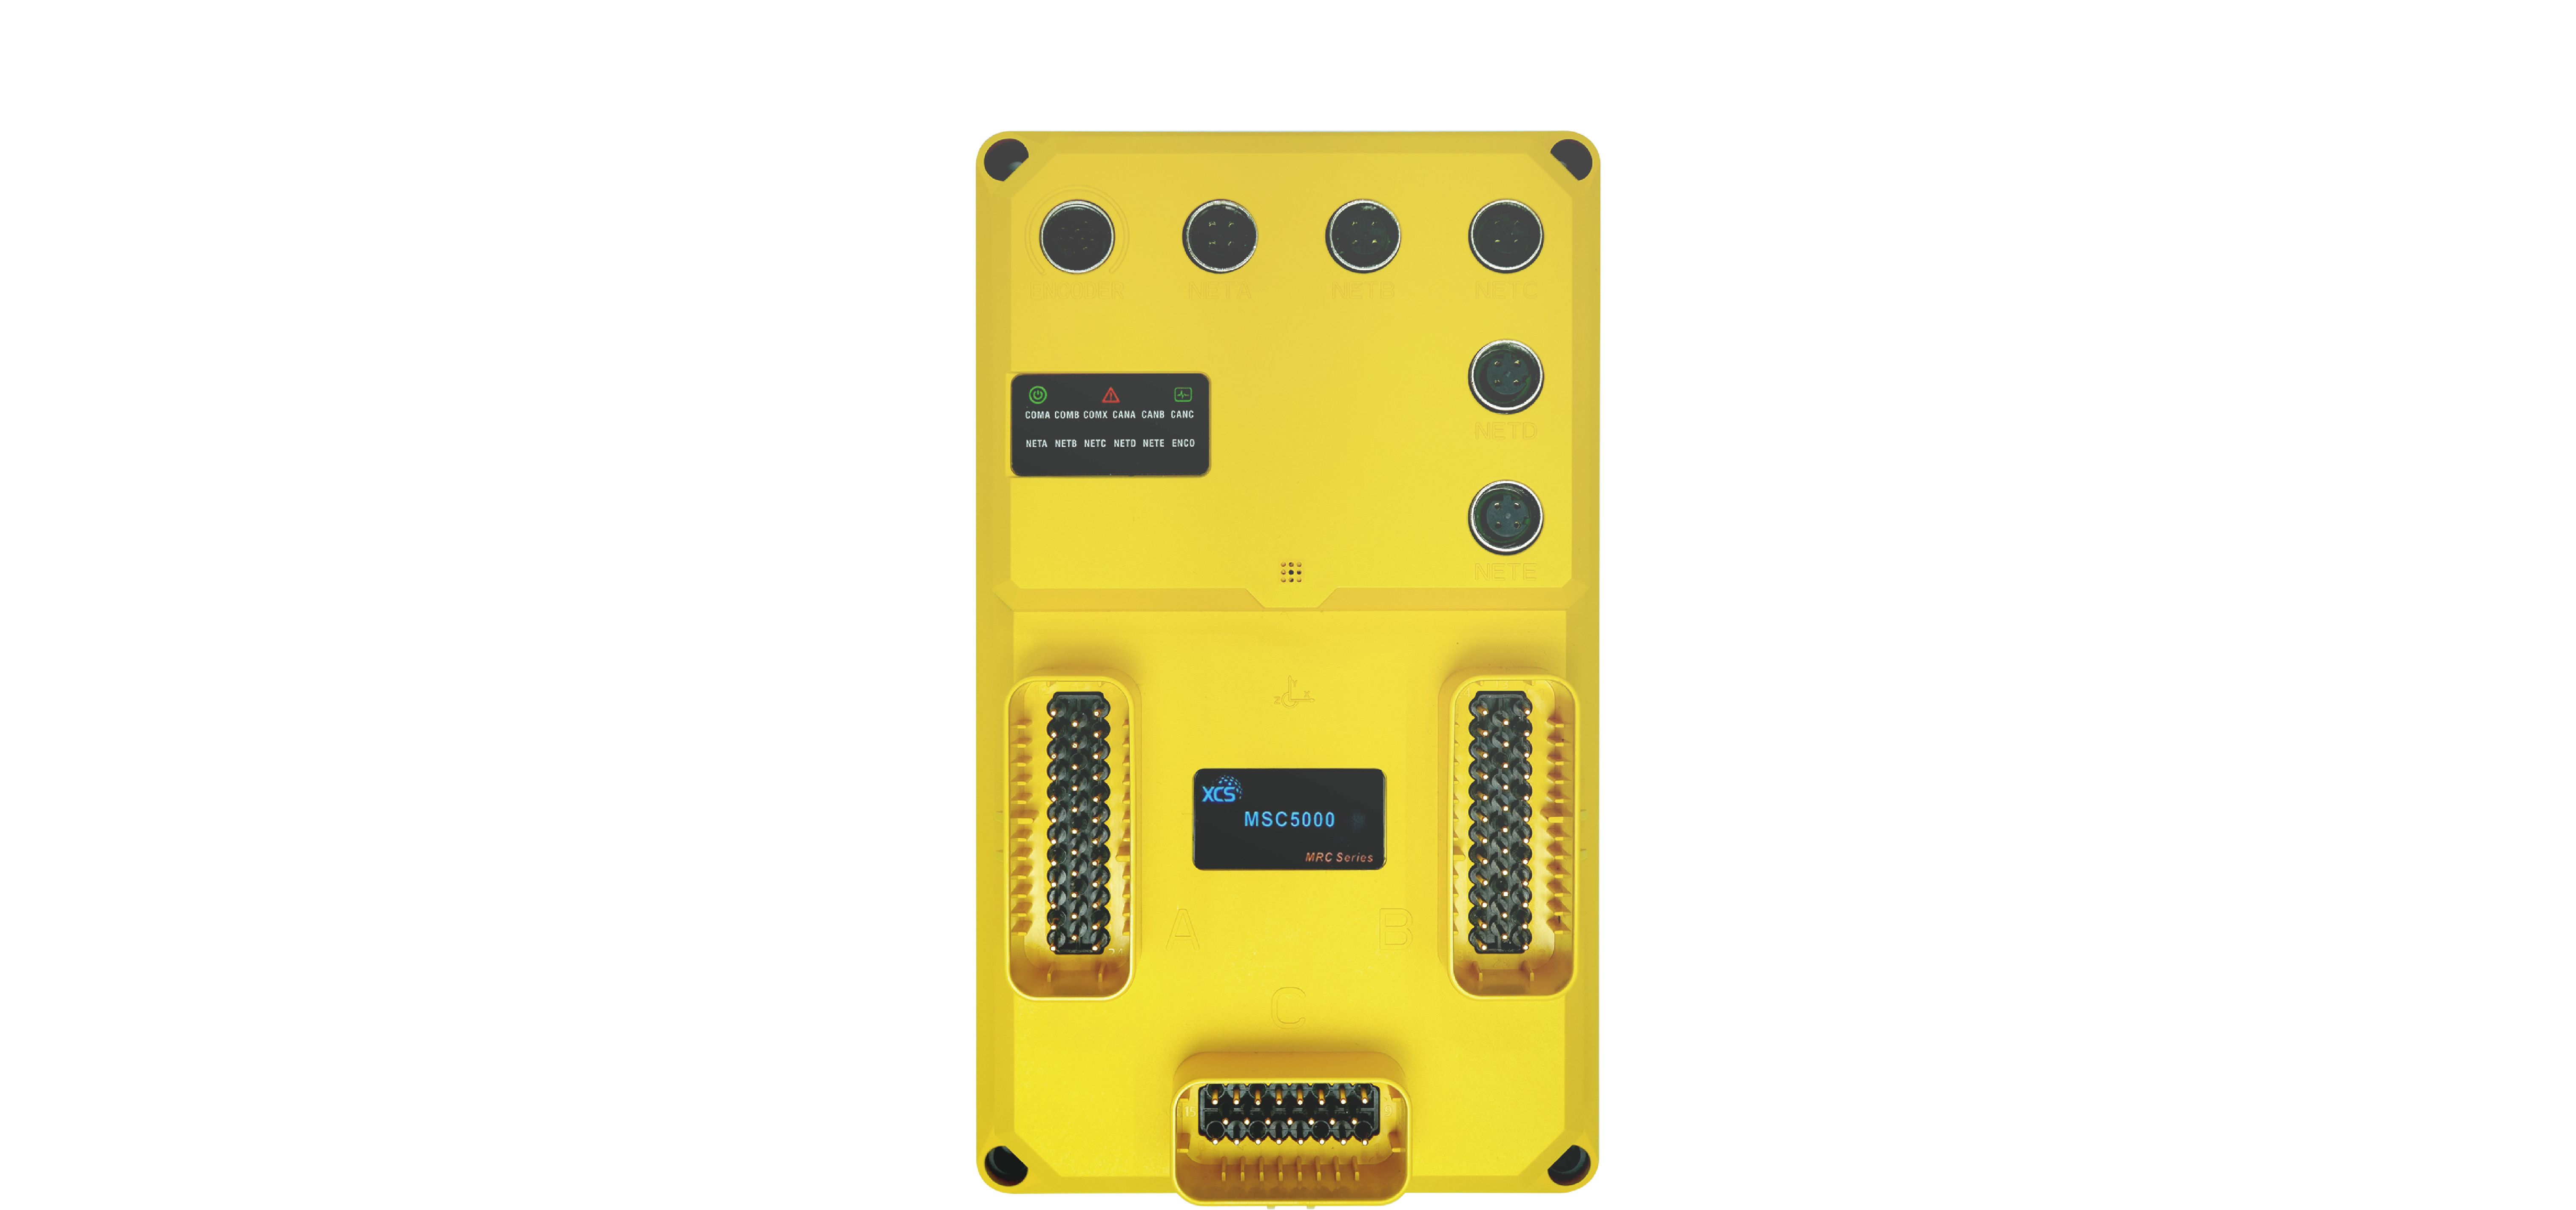


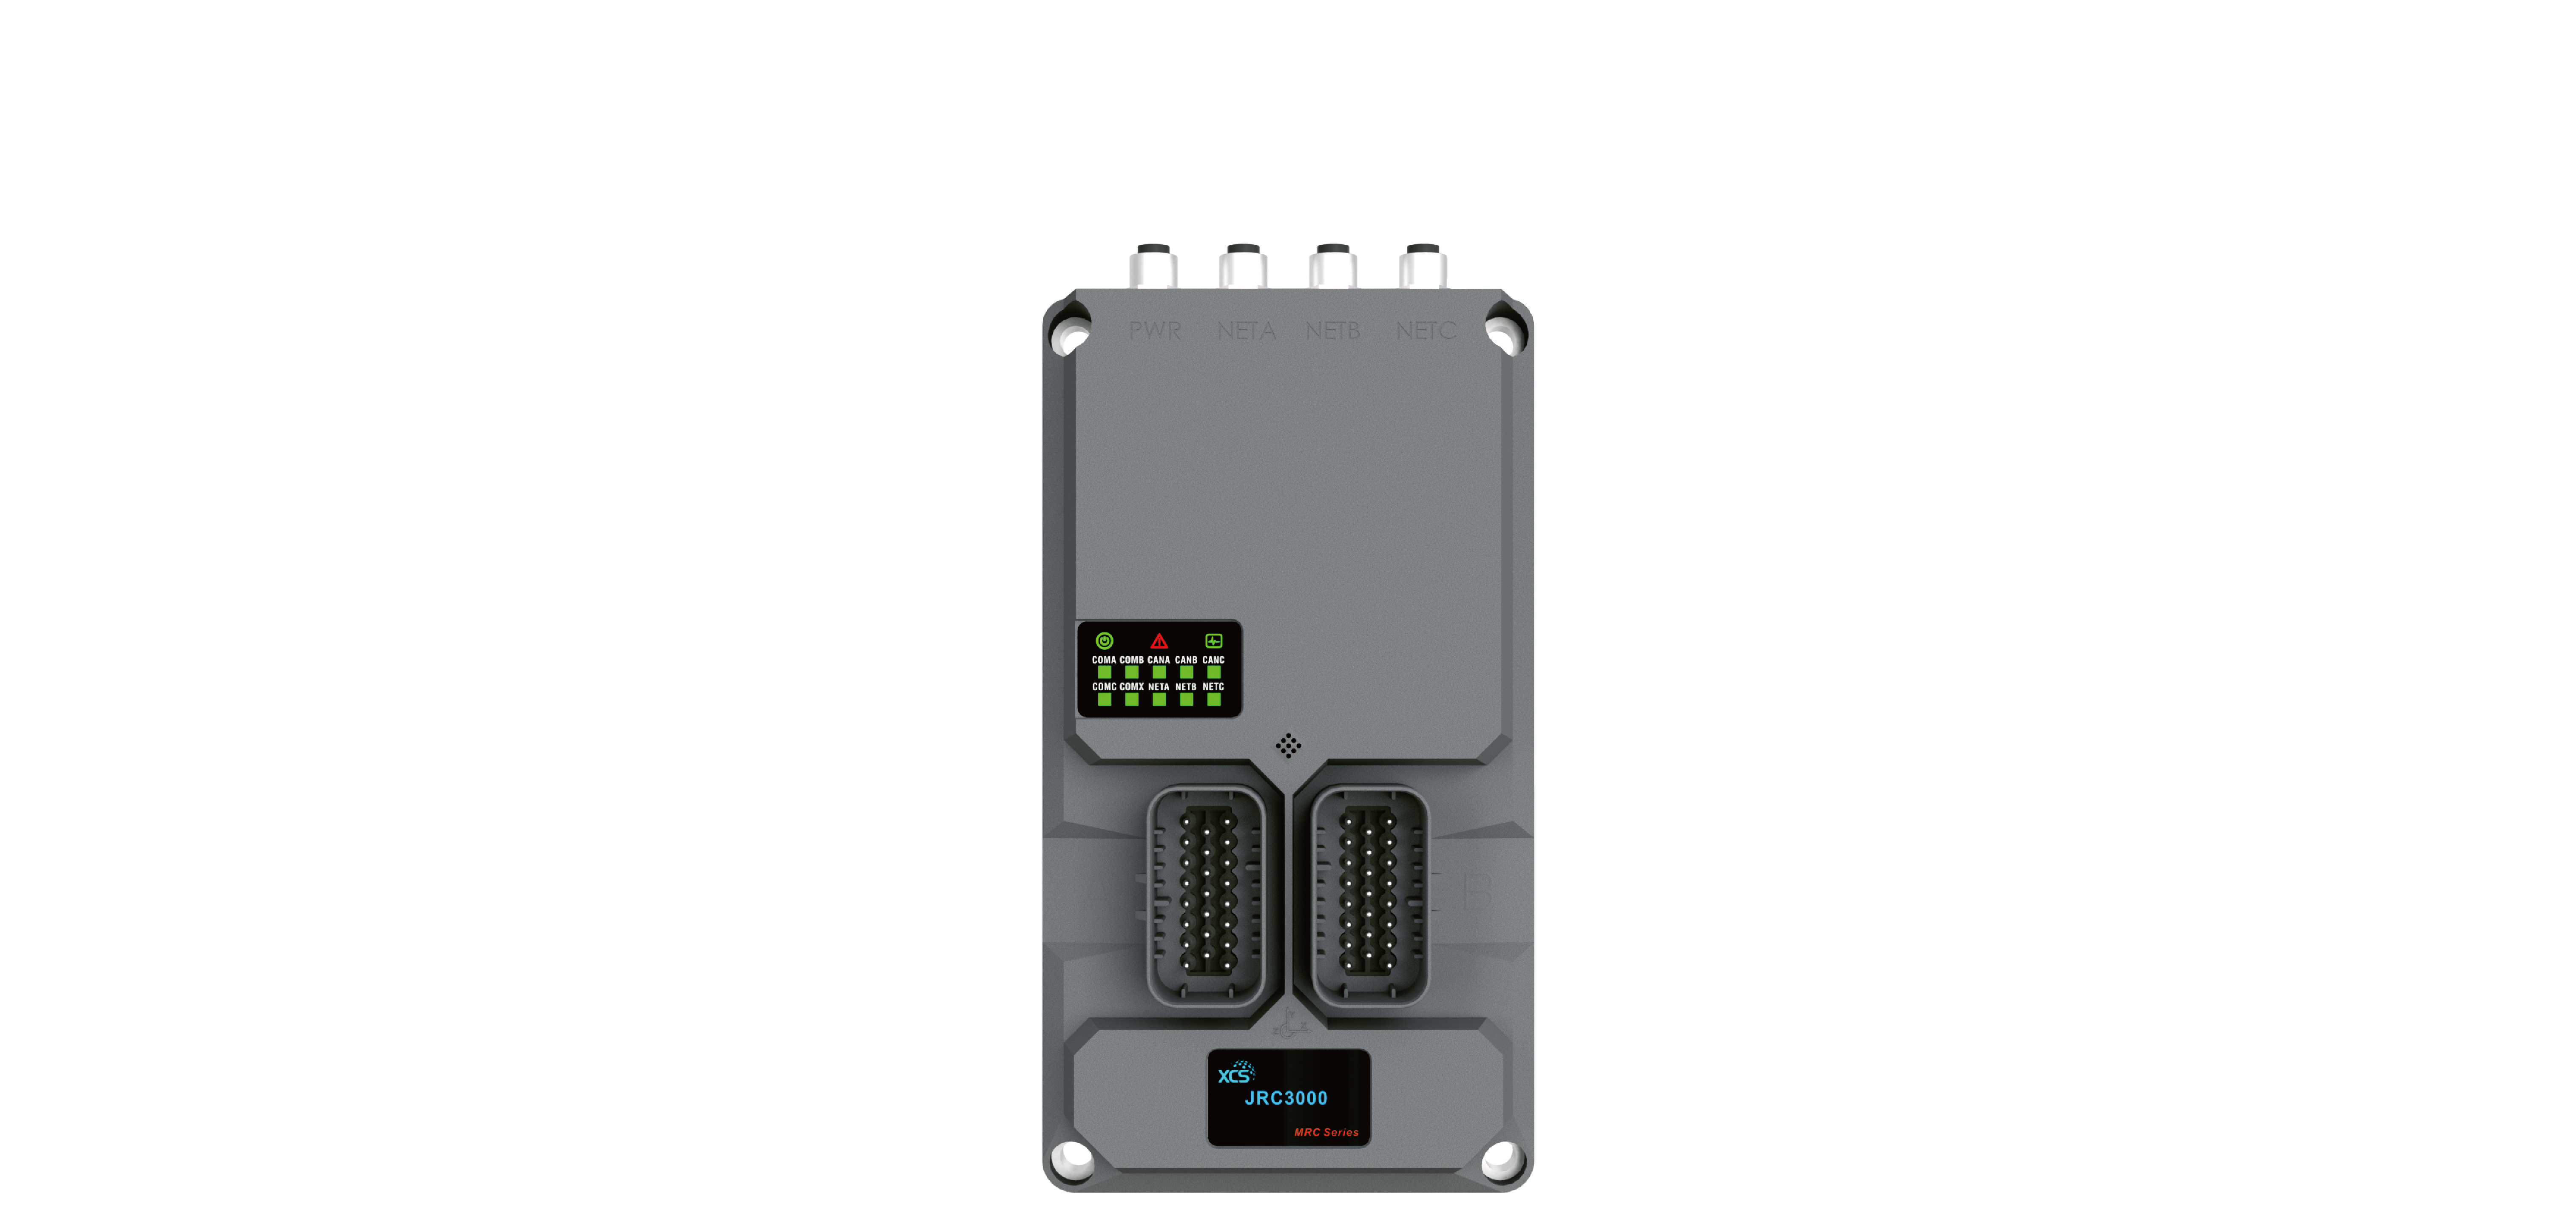



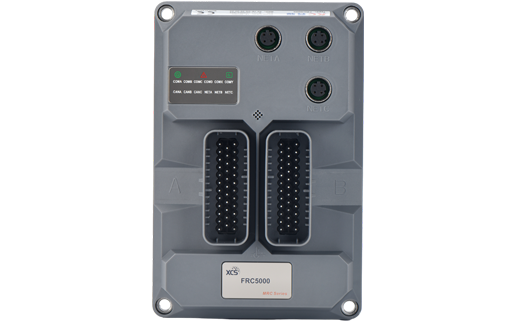
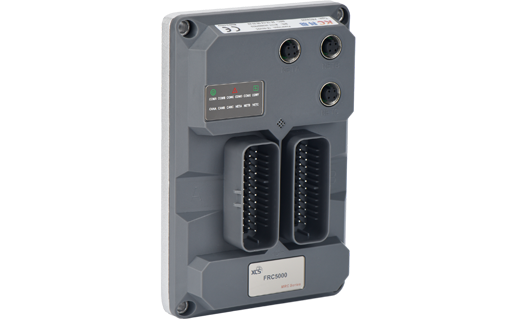
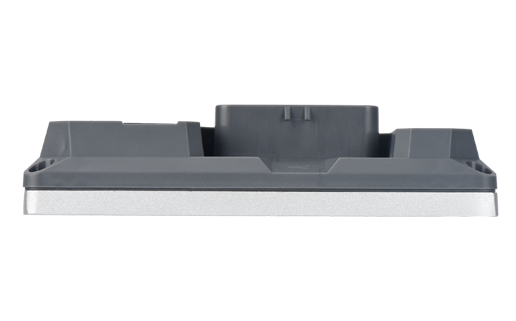
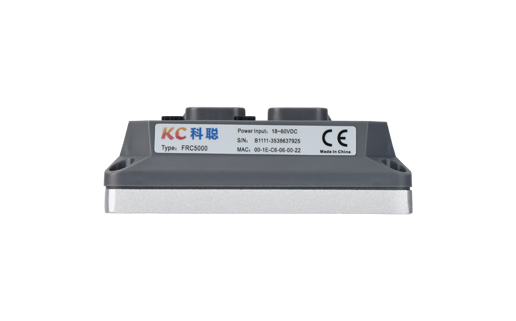
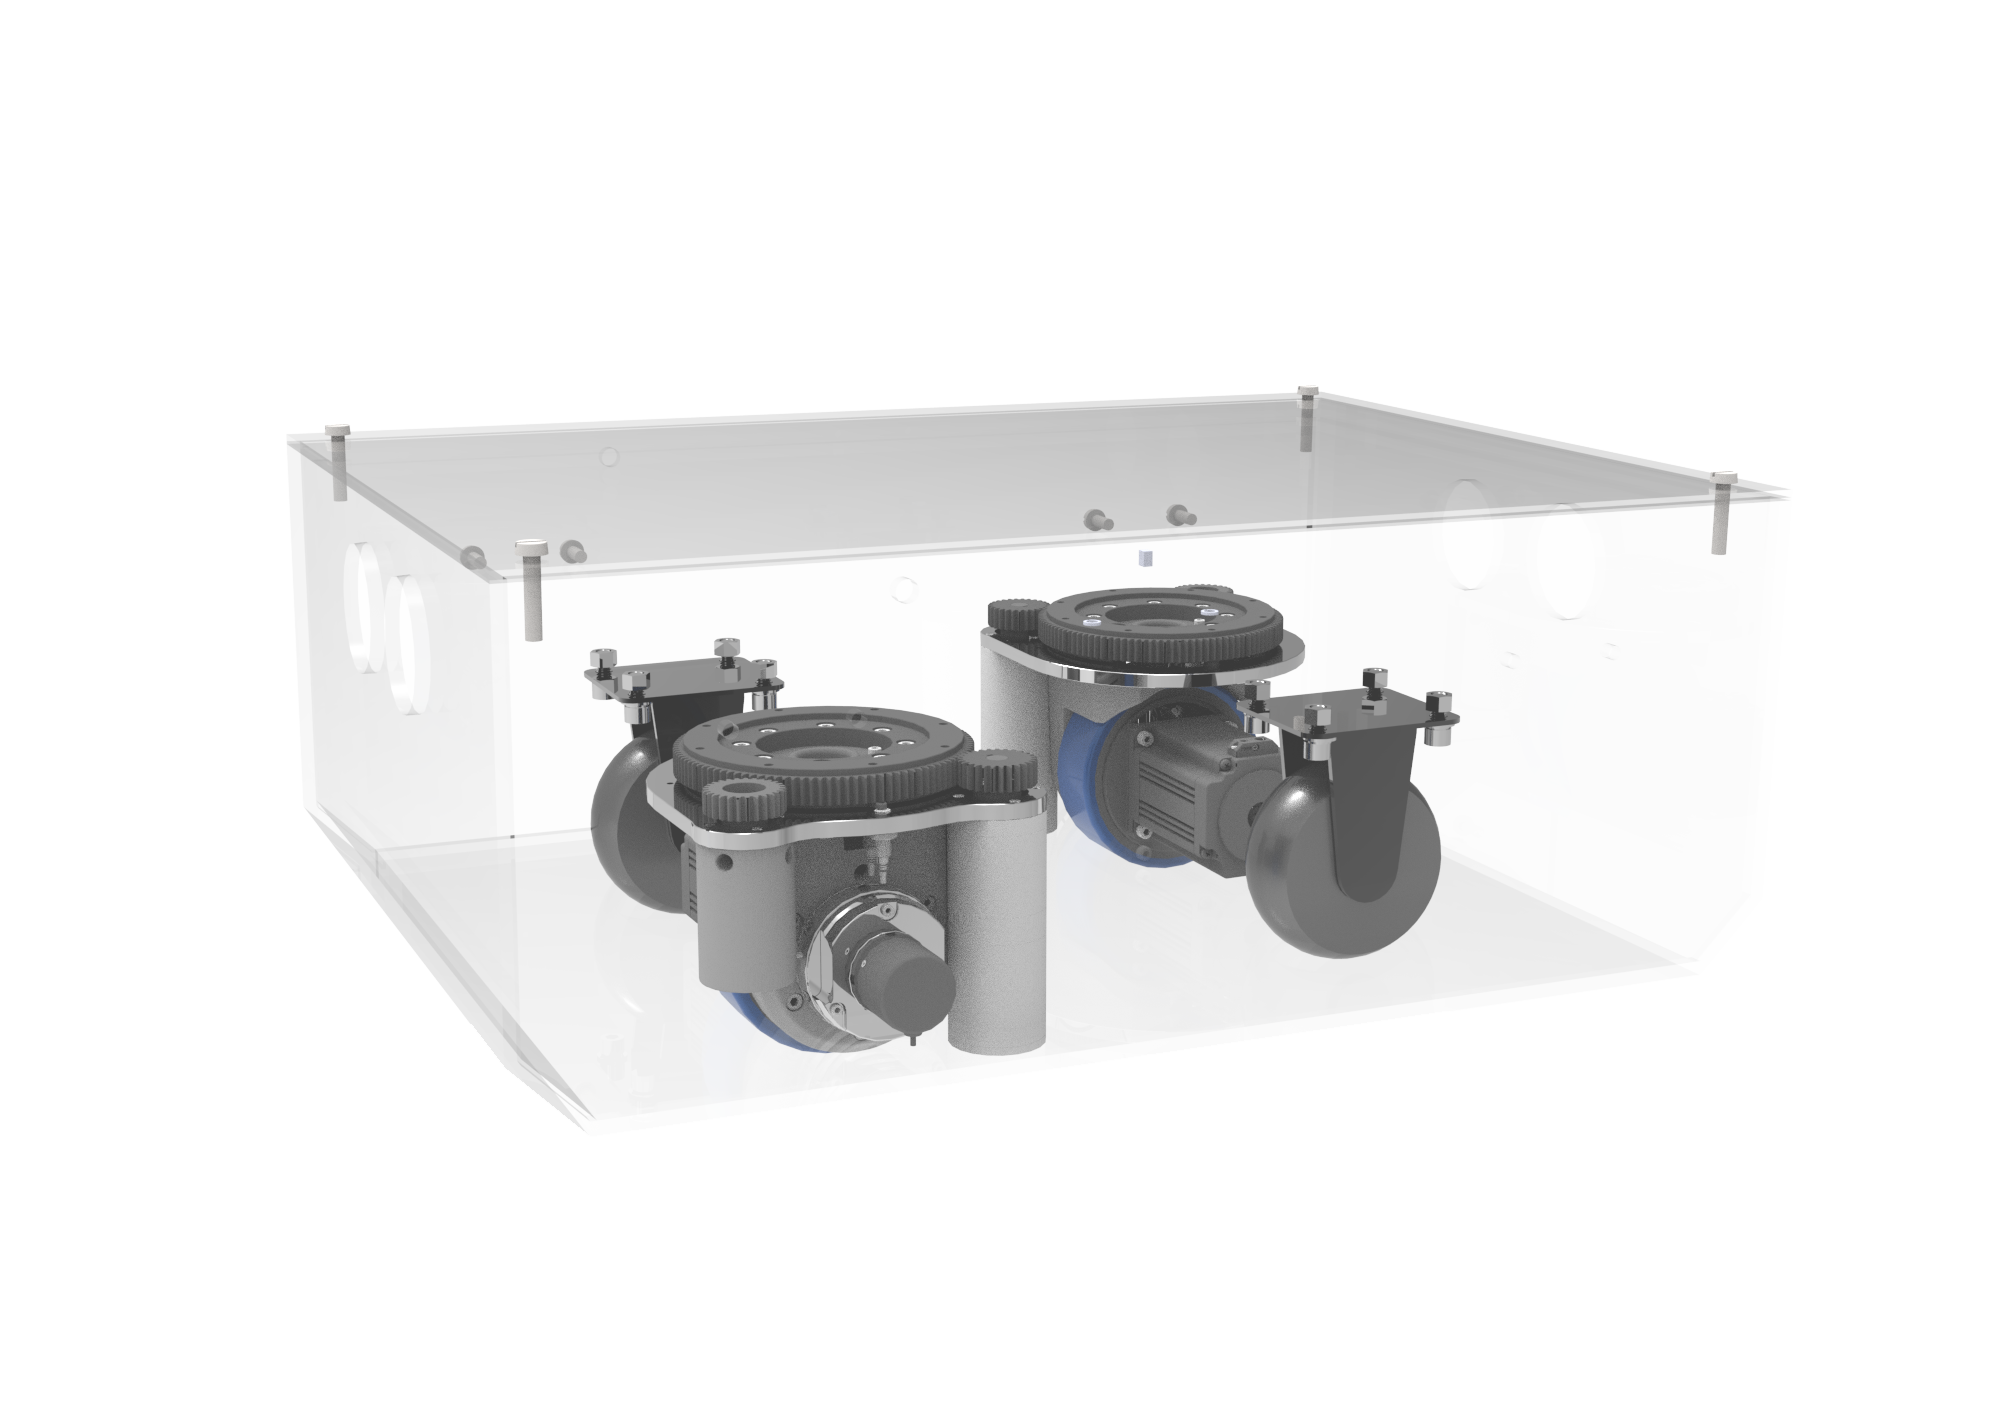
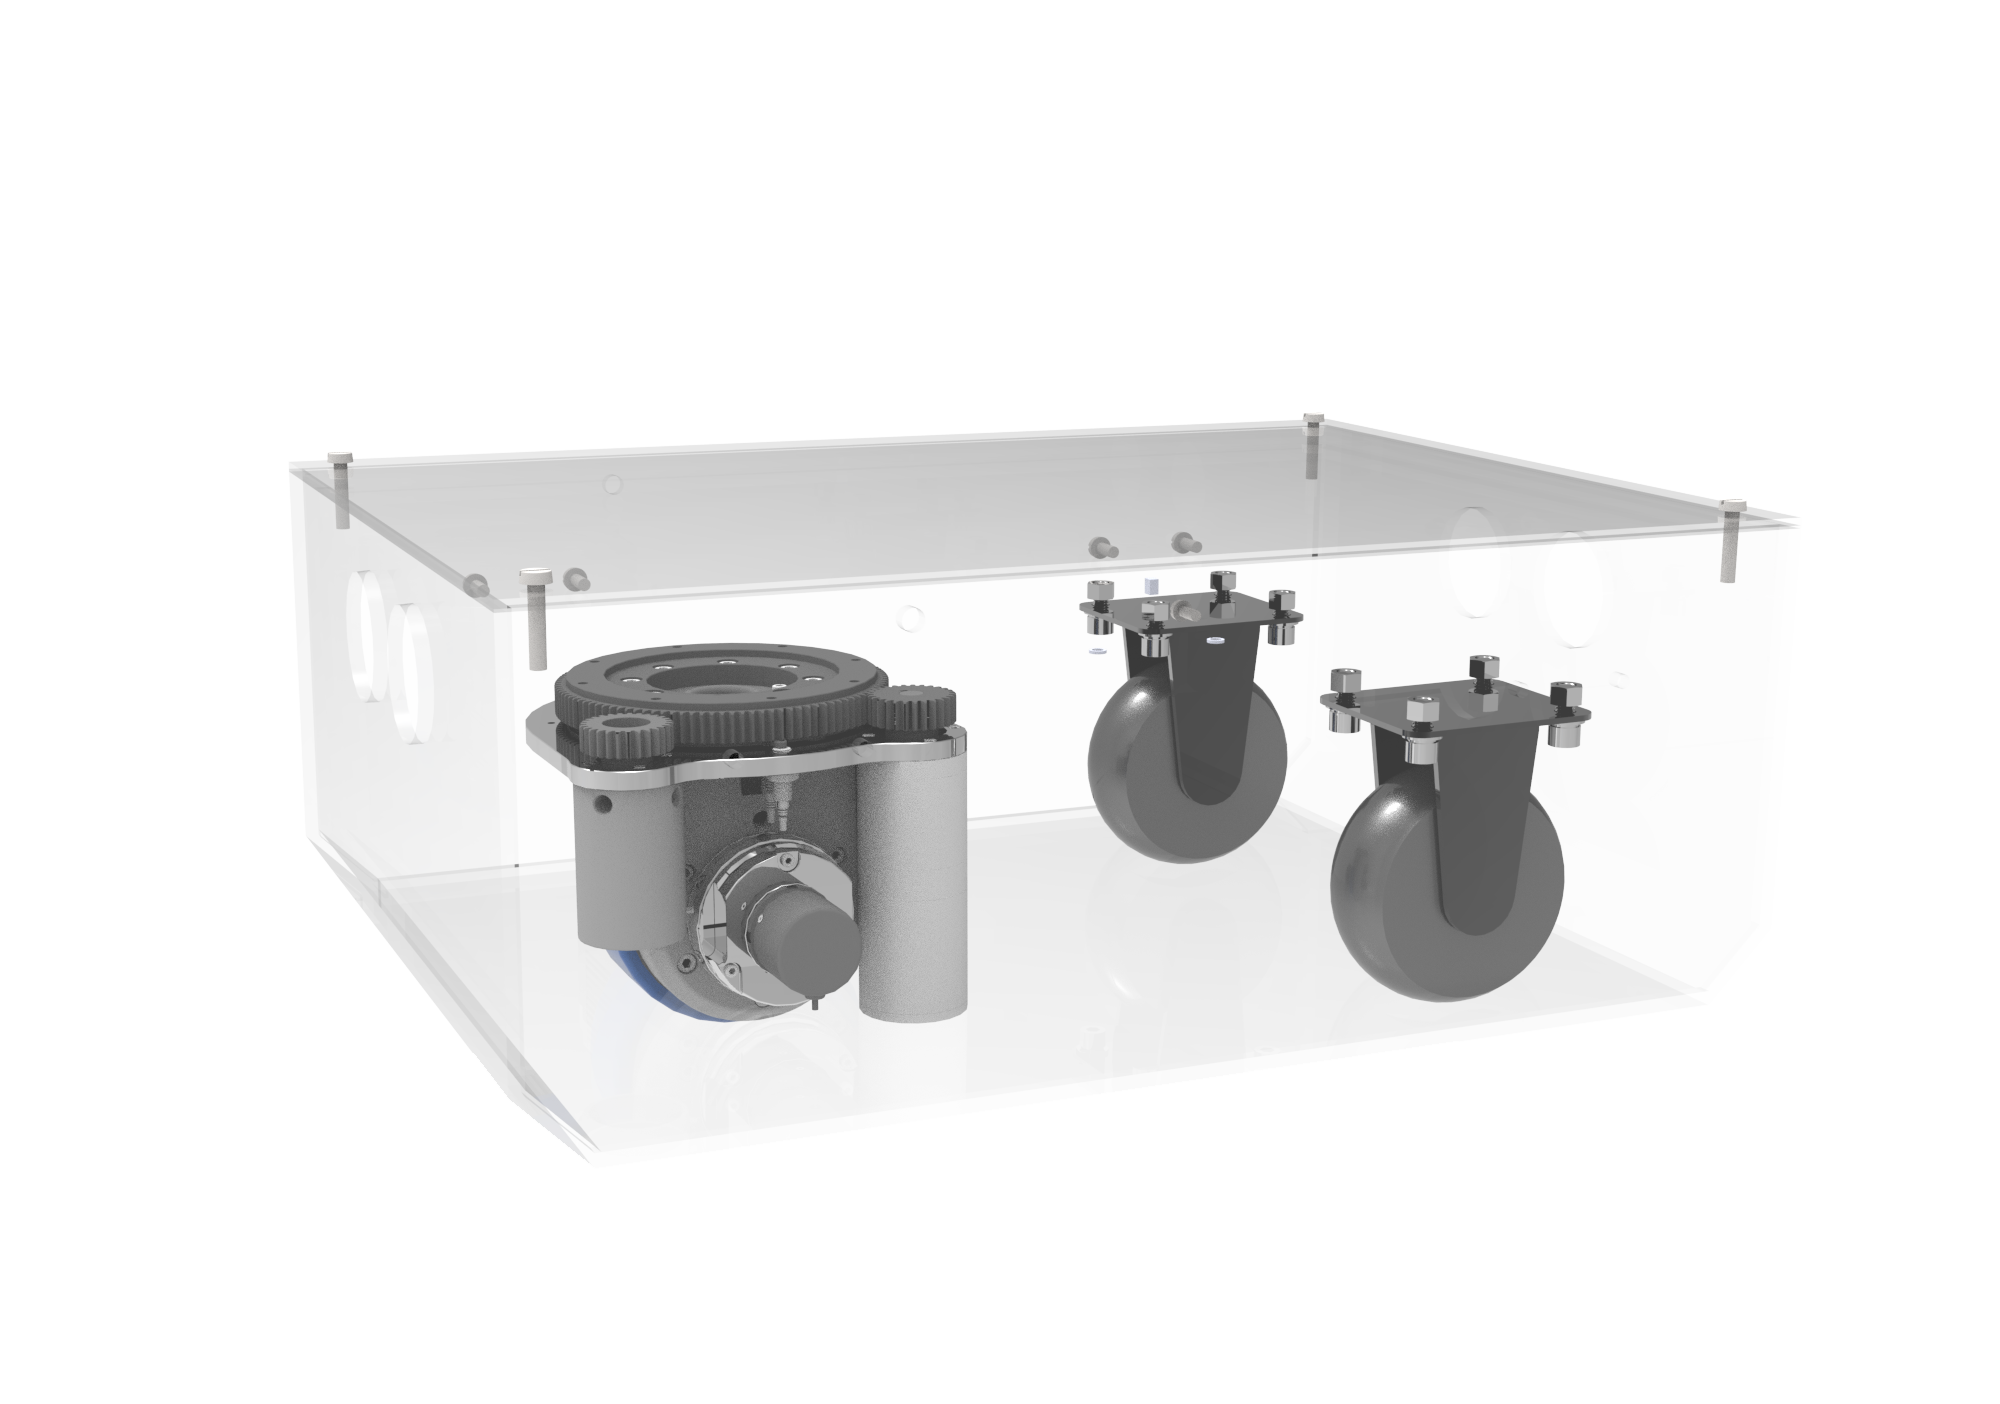


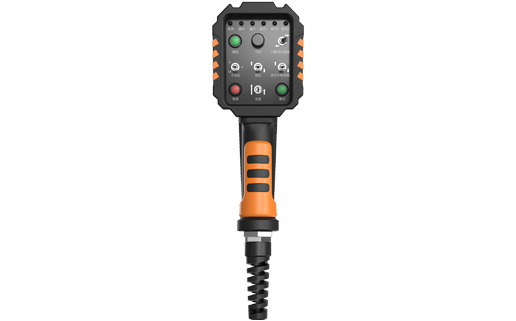
Model | FRC5000-L005 | FRC5000-L006 | FRC5000-L108 | FRC5000-H005 | FRC5000-H006 | FRC5000-H108 |
Description | Fork-type mobile robot controller (single steering wheel) | Fork-type mobile robot controller (double steering wheels) | Fork-type mobile robot controller (four steering wheels) | Fork-type mobile robot controller (single steering wheel) | Fork-type mobile robot controller (double steering wheels) | 166.5 x 110.5 x 40 |
Size W x H x D(mm) | 166.5 x 110.5 x 40 | 166.5 x 110.5 x 40 | 166.5 x 110.5 x 40 | 166.5 x 110.5 x 40 | 166.5 x 110.5 x 40 | 166.5 x 110.5 x 40 |
Protection level | IP65 | IP65 | IP65 | IP65 | IP65 | IP65 |
Temperature | ≥-25°C,≤+70°C | ≥-25°C,≤+70°C | ≥-25°C,≤+70°C | ≥-25°C,≤+70°C | ≥-25°C,≤+70°C | ≥-25°C,≤+70°C |
Humidity | 10%~90%RH no-condensing | 10%~90%RH no-condensing | 10%~90%RH no-condensing | 10%~90%RH no-condensing | 10%~90%RH no-condensing | 10%~90%RH no-condensing |
EMC | Ind Level 3 | Ind Level 3 | Ind Level 3 | Ind Level 3 | Ind Level 3 | Ind Level 3 |
IMU | √ | √ | √ | √ | √ | √ |
Differential chassis motion model | × | × | × | × | Dual-differential assembly chassis | Four-differential assembly chassis |
Rudder base motion model | Single steering wheel | Dual steering wheels | Four steering wheels | Single steering wheel | Dual steering wheels | Four steering wheels |
Other chassis motion models | × | Dual differential assembly | Four differential assembly, four steering wheel assembly | × | × | × |
Laser navigation | √ | √ | √ | √ | √ | √ |
QR code navigation | √ | Optional equipment | √ | × | × | × |
Magnetic navigation | Optional equipment | × | × | × | × | × |
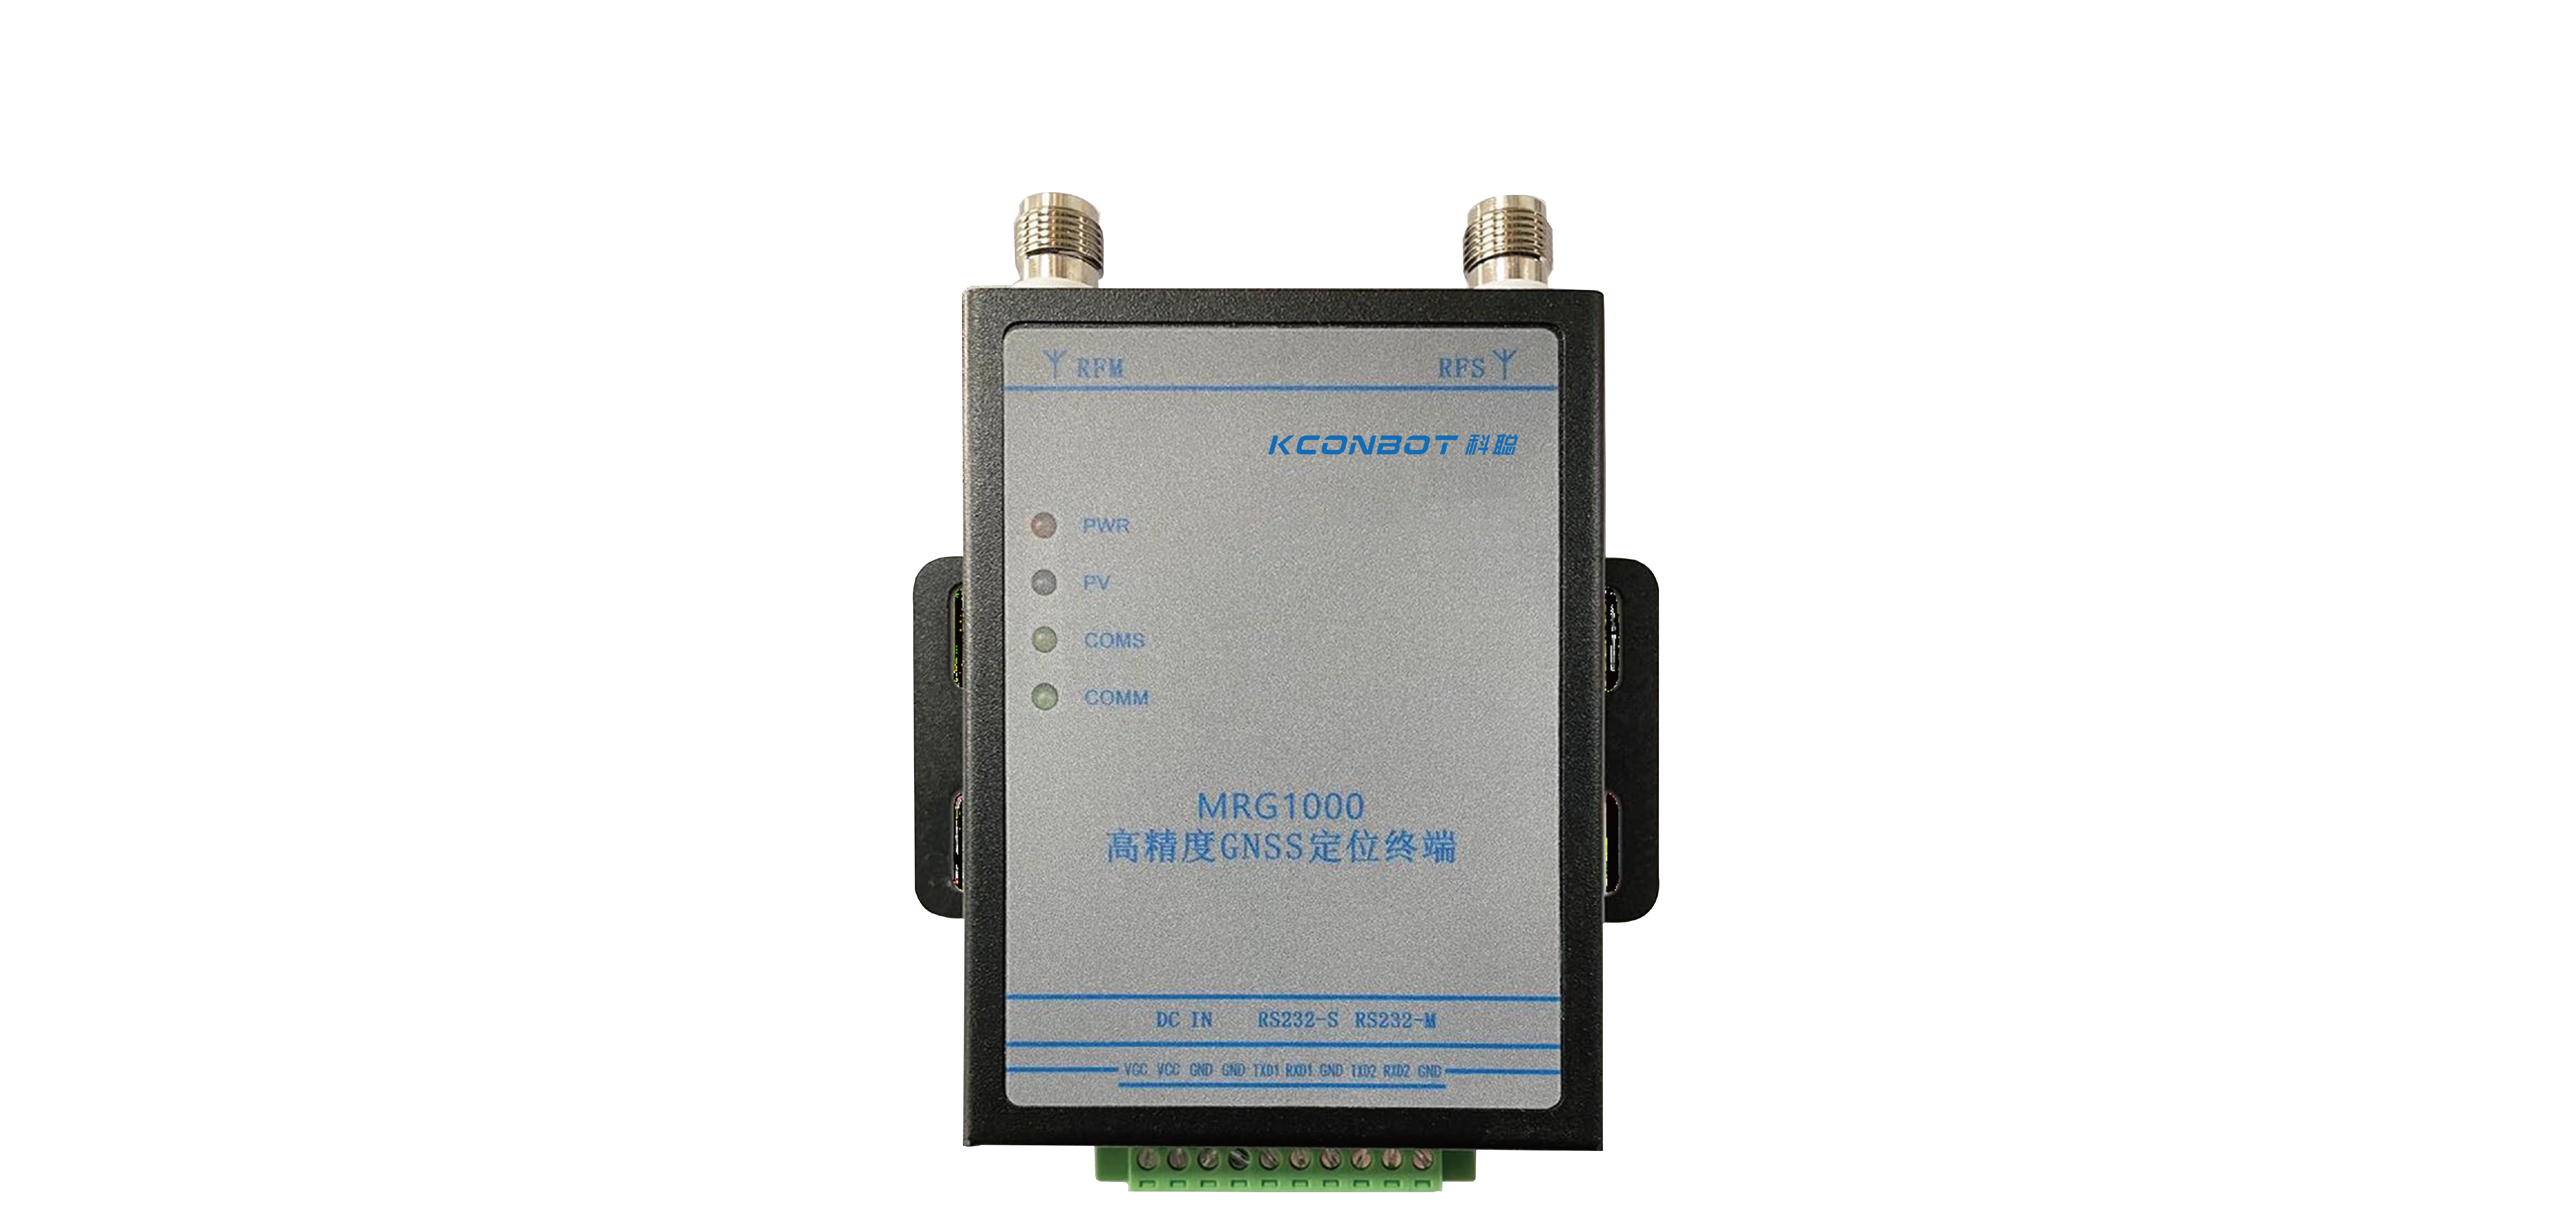
Other navigation methods | × | × | × | GNSS navigation, hybrid navigation | GNSS navigation, hybrid navigation | GNSS navigation, hybrid navigation |
Navigation positioning accuracy | Laser Natural (SLAM) navigation ±5mm, Laser with Feedback navigation ±2mm, Magnetic navigation ±10mm | Laser Natural (SLAM) navigation ±5mm, Laser with Feedback navigation ±2mm, Magnetic navigation ±10mm | Laser Natural (SLAM) navigation ±5mm, Laser with Feedback navigation ±2mm, Magnetic navigation ±10mm | 3D laser navigator: 10mm; GNSS navigation: 50mm; GNSS + 3D laser hybrid navigation: ±25mm | 3D laser navigator: 10mm; GNSS navigation: 50mm; GNSS + 3D laser hybrid navigation: ±25mm | 3D laser navigator: 10mm; GNSS navigation: 50mm; GNSS + 3D laser hybrid navigation: ±25mm |
Angle control accuracy | ±0.5° | ±0.5° | ±0.5° | ±0.5° | ±0.5° | ±0.5° |
Map area | ≤400000㎡ | ≤400000㎡ | ≤400000㎡ | ≤400000㎡ | ≤400000㎡ | ≤400000㎡ |
CAN (Channel) | 3 | 3 | 3 | 3 | 3 | 3 |
RS485/RS232/RS422 (Channel) | 3/1/× | 3/1/× | 3/1/× | 3/1/× | 3/1/× | 3/1/× |
Reused communication port (channel) | 1 (Compatible with CAN/RS485/RS232) | 1 (Compatible with CAN/RS485/RS232) | 1 (Compatible with CAN/RS485/RS232) | 1 (Compatible with CAN/RS485/RS232) | 1 (Compatible with CAN/RS485/RS232) | 1 (Compatible with CAN/RS485/RS232) |
PWM (channel) | 4 | 4 | 4 | 4 | 4 | 4 |
AI/AO | × | × | × | × | × | × |
DI/DO/DIO | 20/12/4 | 20/12/4 | 20/12/4 | 20/12/4 | 20/12/4 | 20/12/4 |
Encoder (Channel) | 2 | 2 | 2 | 2 | 2 | 2 |
Audio interface | 1 | 1 | 1 | 1 | 1 | 1 |
Wired Industrial Ethernet | 3 | 3 | 3 | 3 | 3 | 3 |
Wireless debugging interface | √ | √ | √ | √ | √ | √ |
Robot design software | √ | √ | √ | √ | √ | √ |
Robot application software | √ | √ | √ | √ | √ | √ |
Robot monitoring and scheduling software | Optional equipment | Optional equipment | Optional equipment | Optional equipment | Optional equipment | Optional equipment |
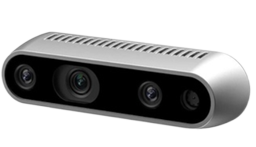
Expand the function | Pallet recognition, secondary positioning of markers, navigation laser-assisted obstacle avoidance, 3D vision-based obstacle avoidance | Visual positioning, material leg recognition, secondary positioning of markers, navigation laser-assisted obstacle avoidance, 3D visual obstacle avoidance | Visual positioning, material leg recognition, secondary positioning of markers, navigation laser-assisted obstacle avoidance, 3D visual obstacle avoidance | Pallet recognition, leg recognition, secondary positioning of markers, navigation laser-assisted obstacle avoidance, 3D vision-based obstacle avoidance | Leg material recognition, secondary positioning of markers, navigation laser-assisted obstacle avoidance, 3D vision-based obstacle avoidance | Leg material recognition, secondary positioning of markers, navigation laser-assisted obstacle avoidance, 3D vision-based obstacle avoidance |
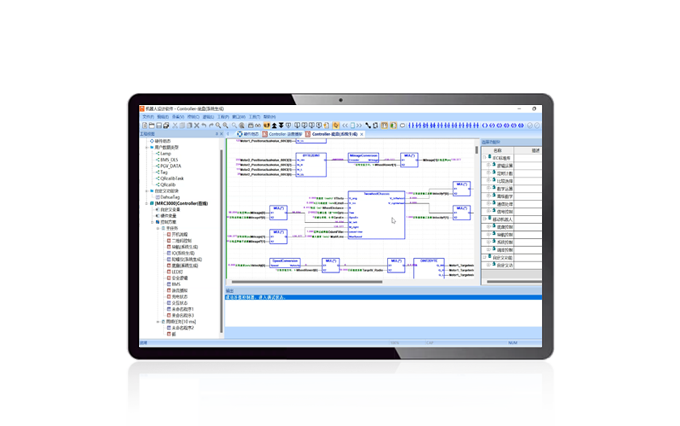
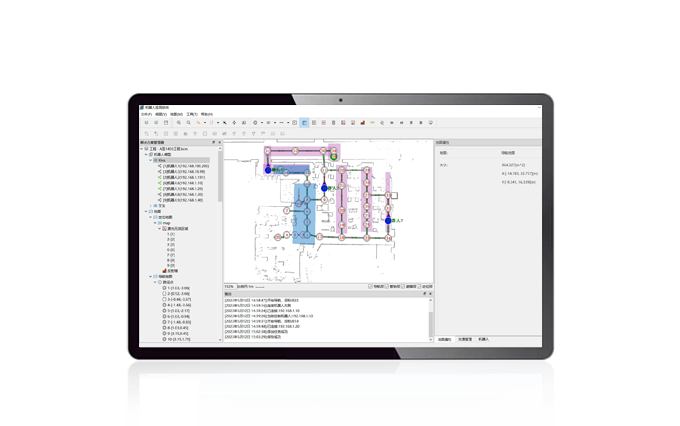

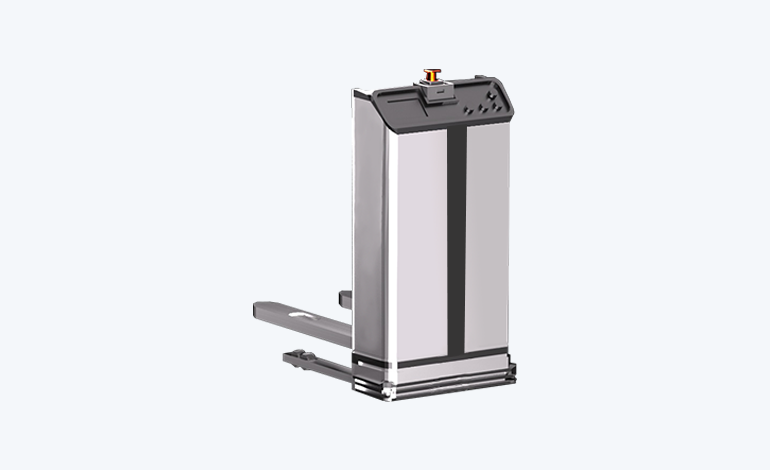
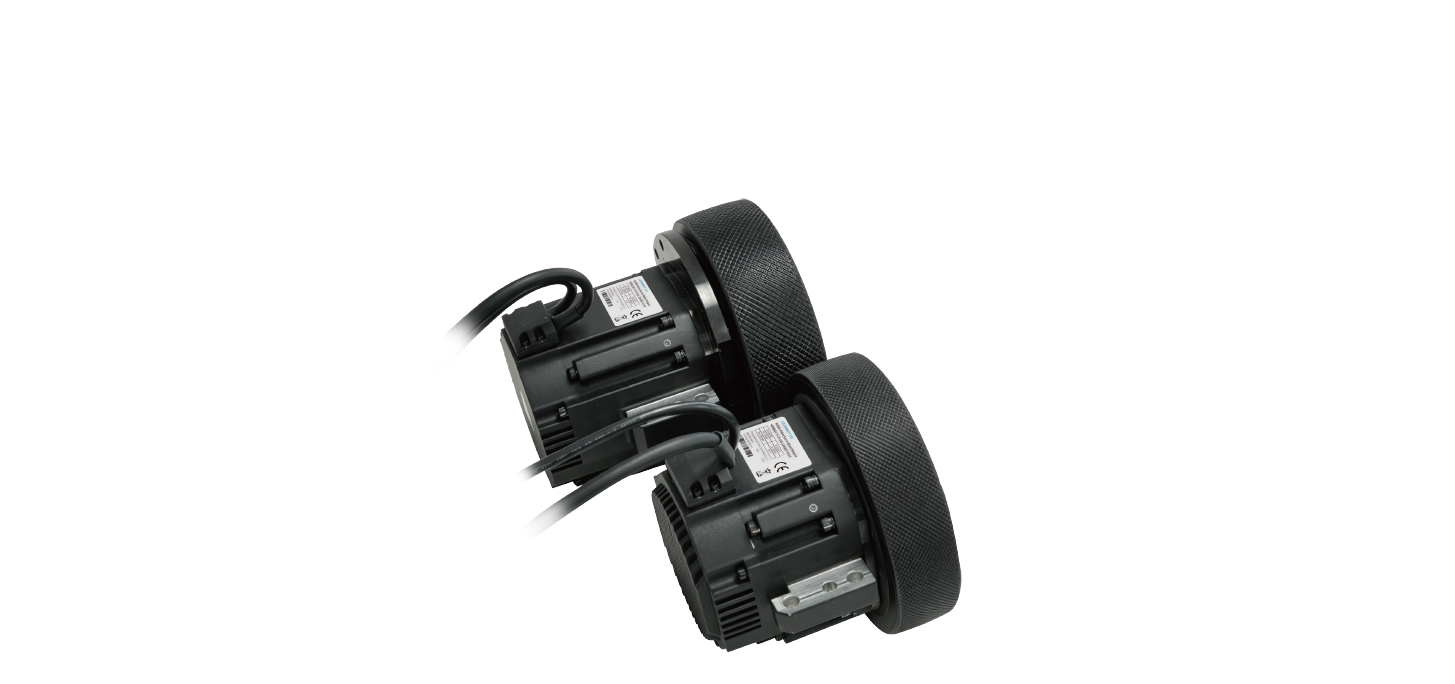
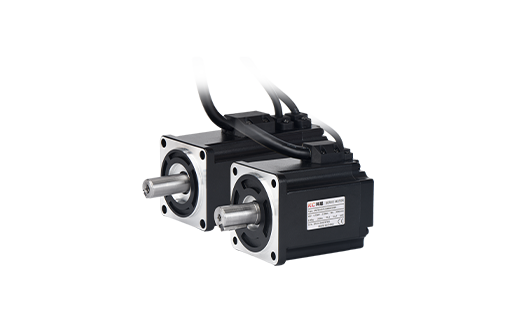
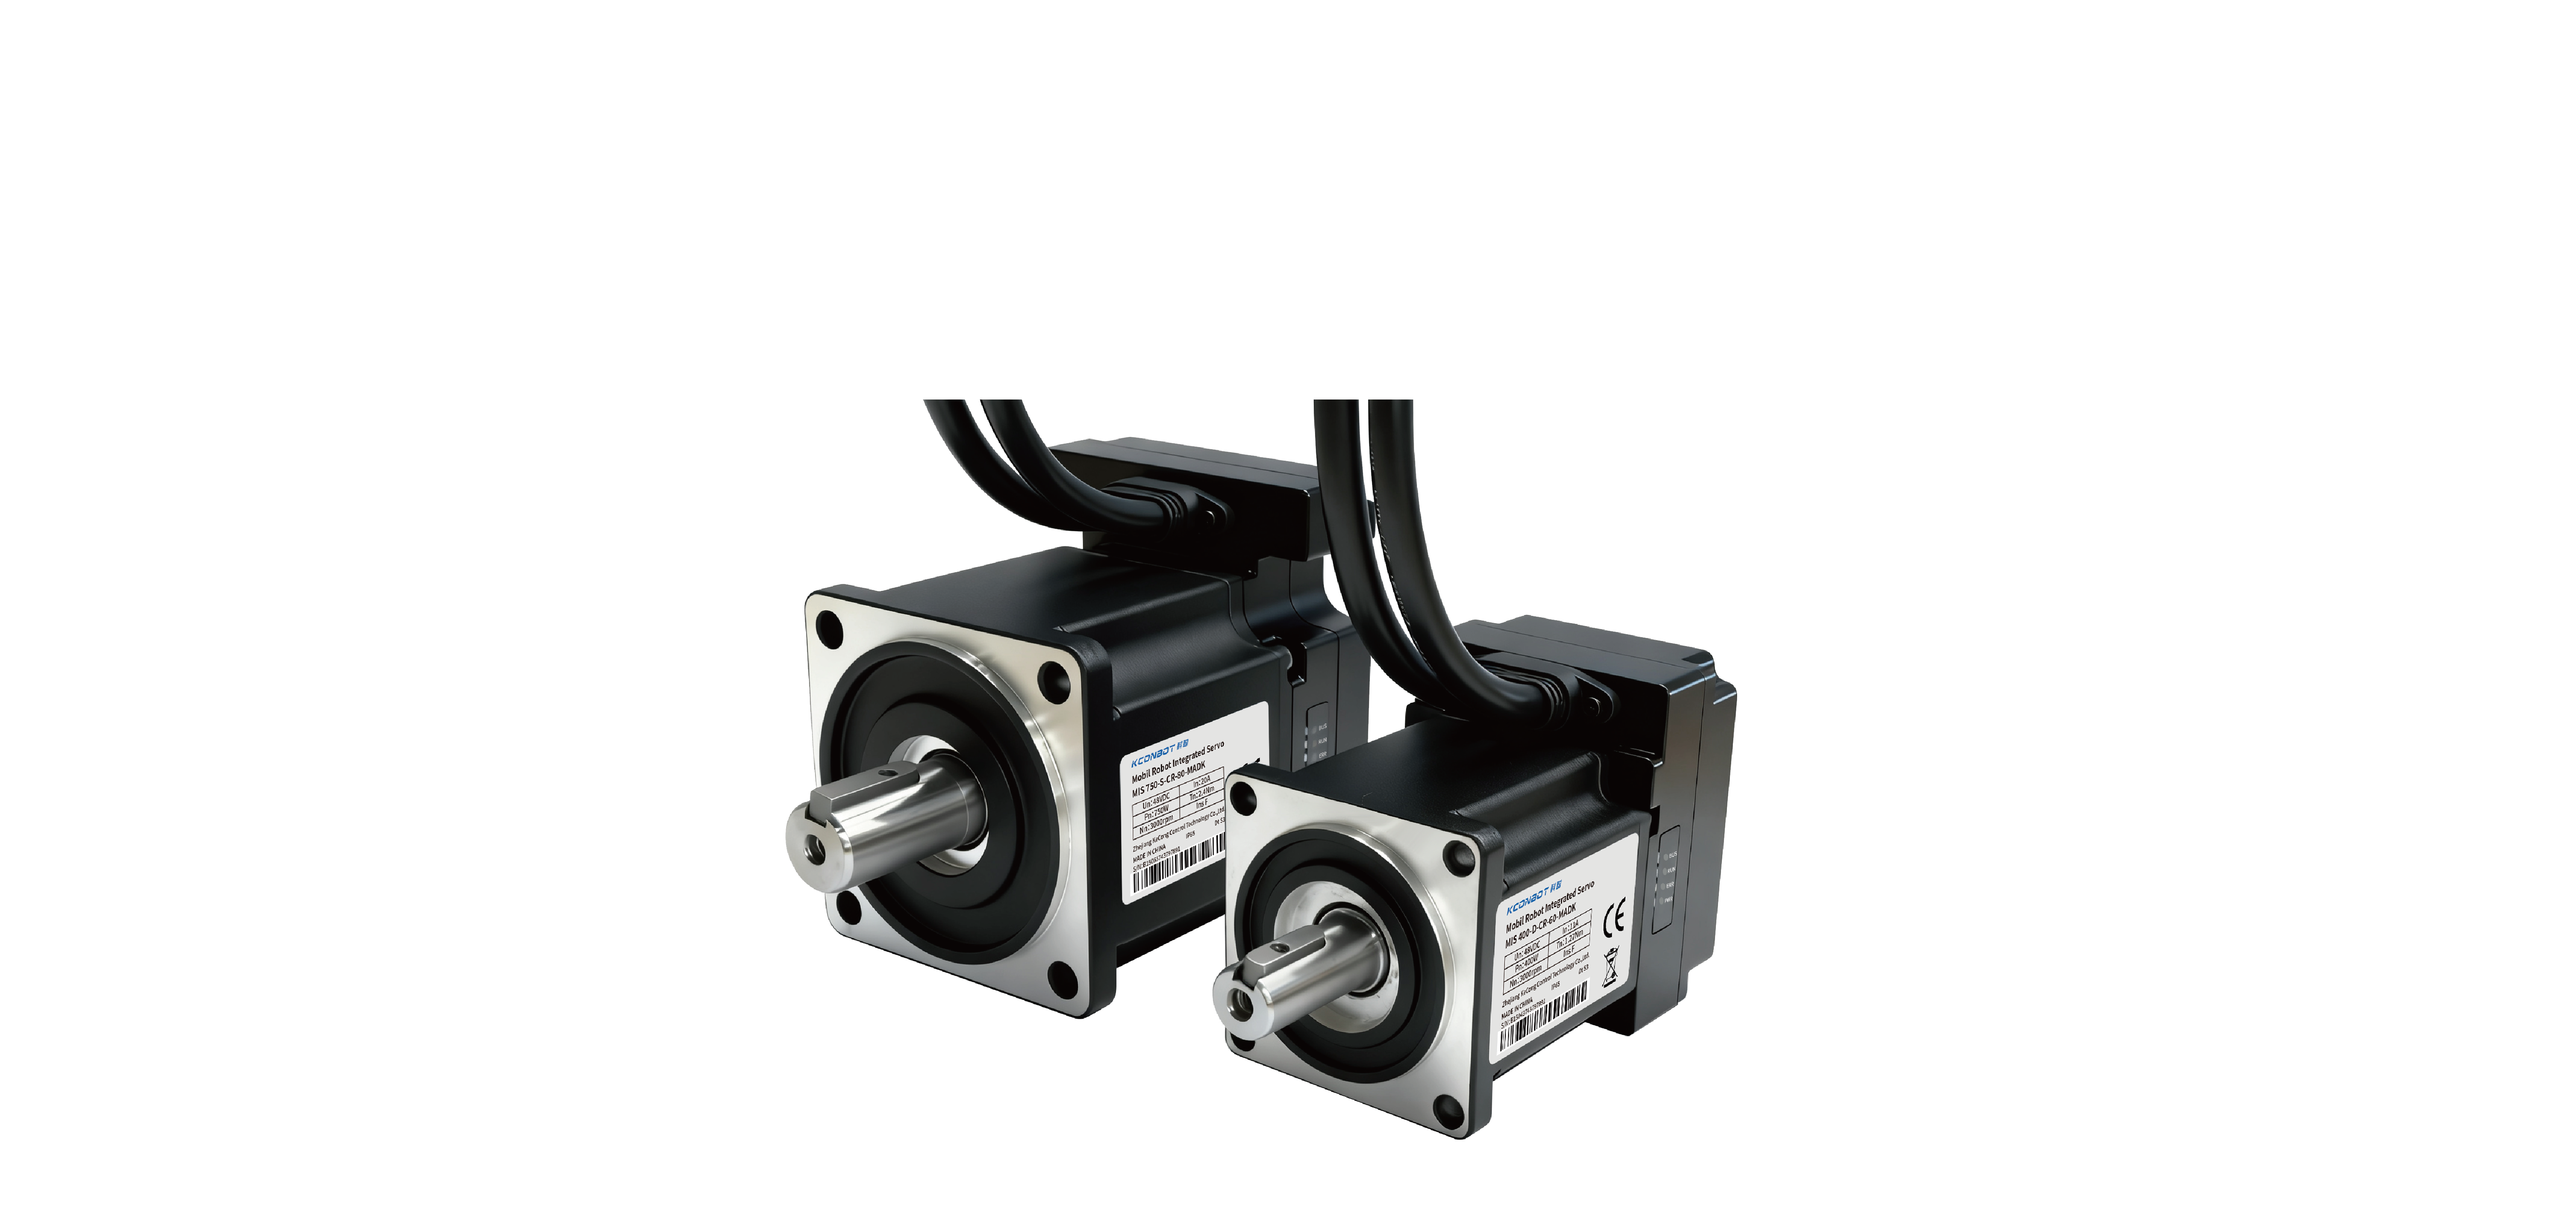
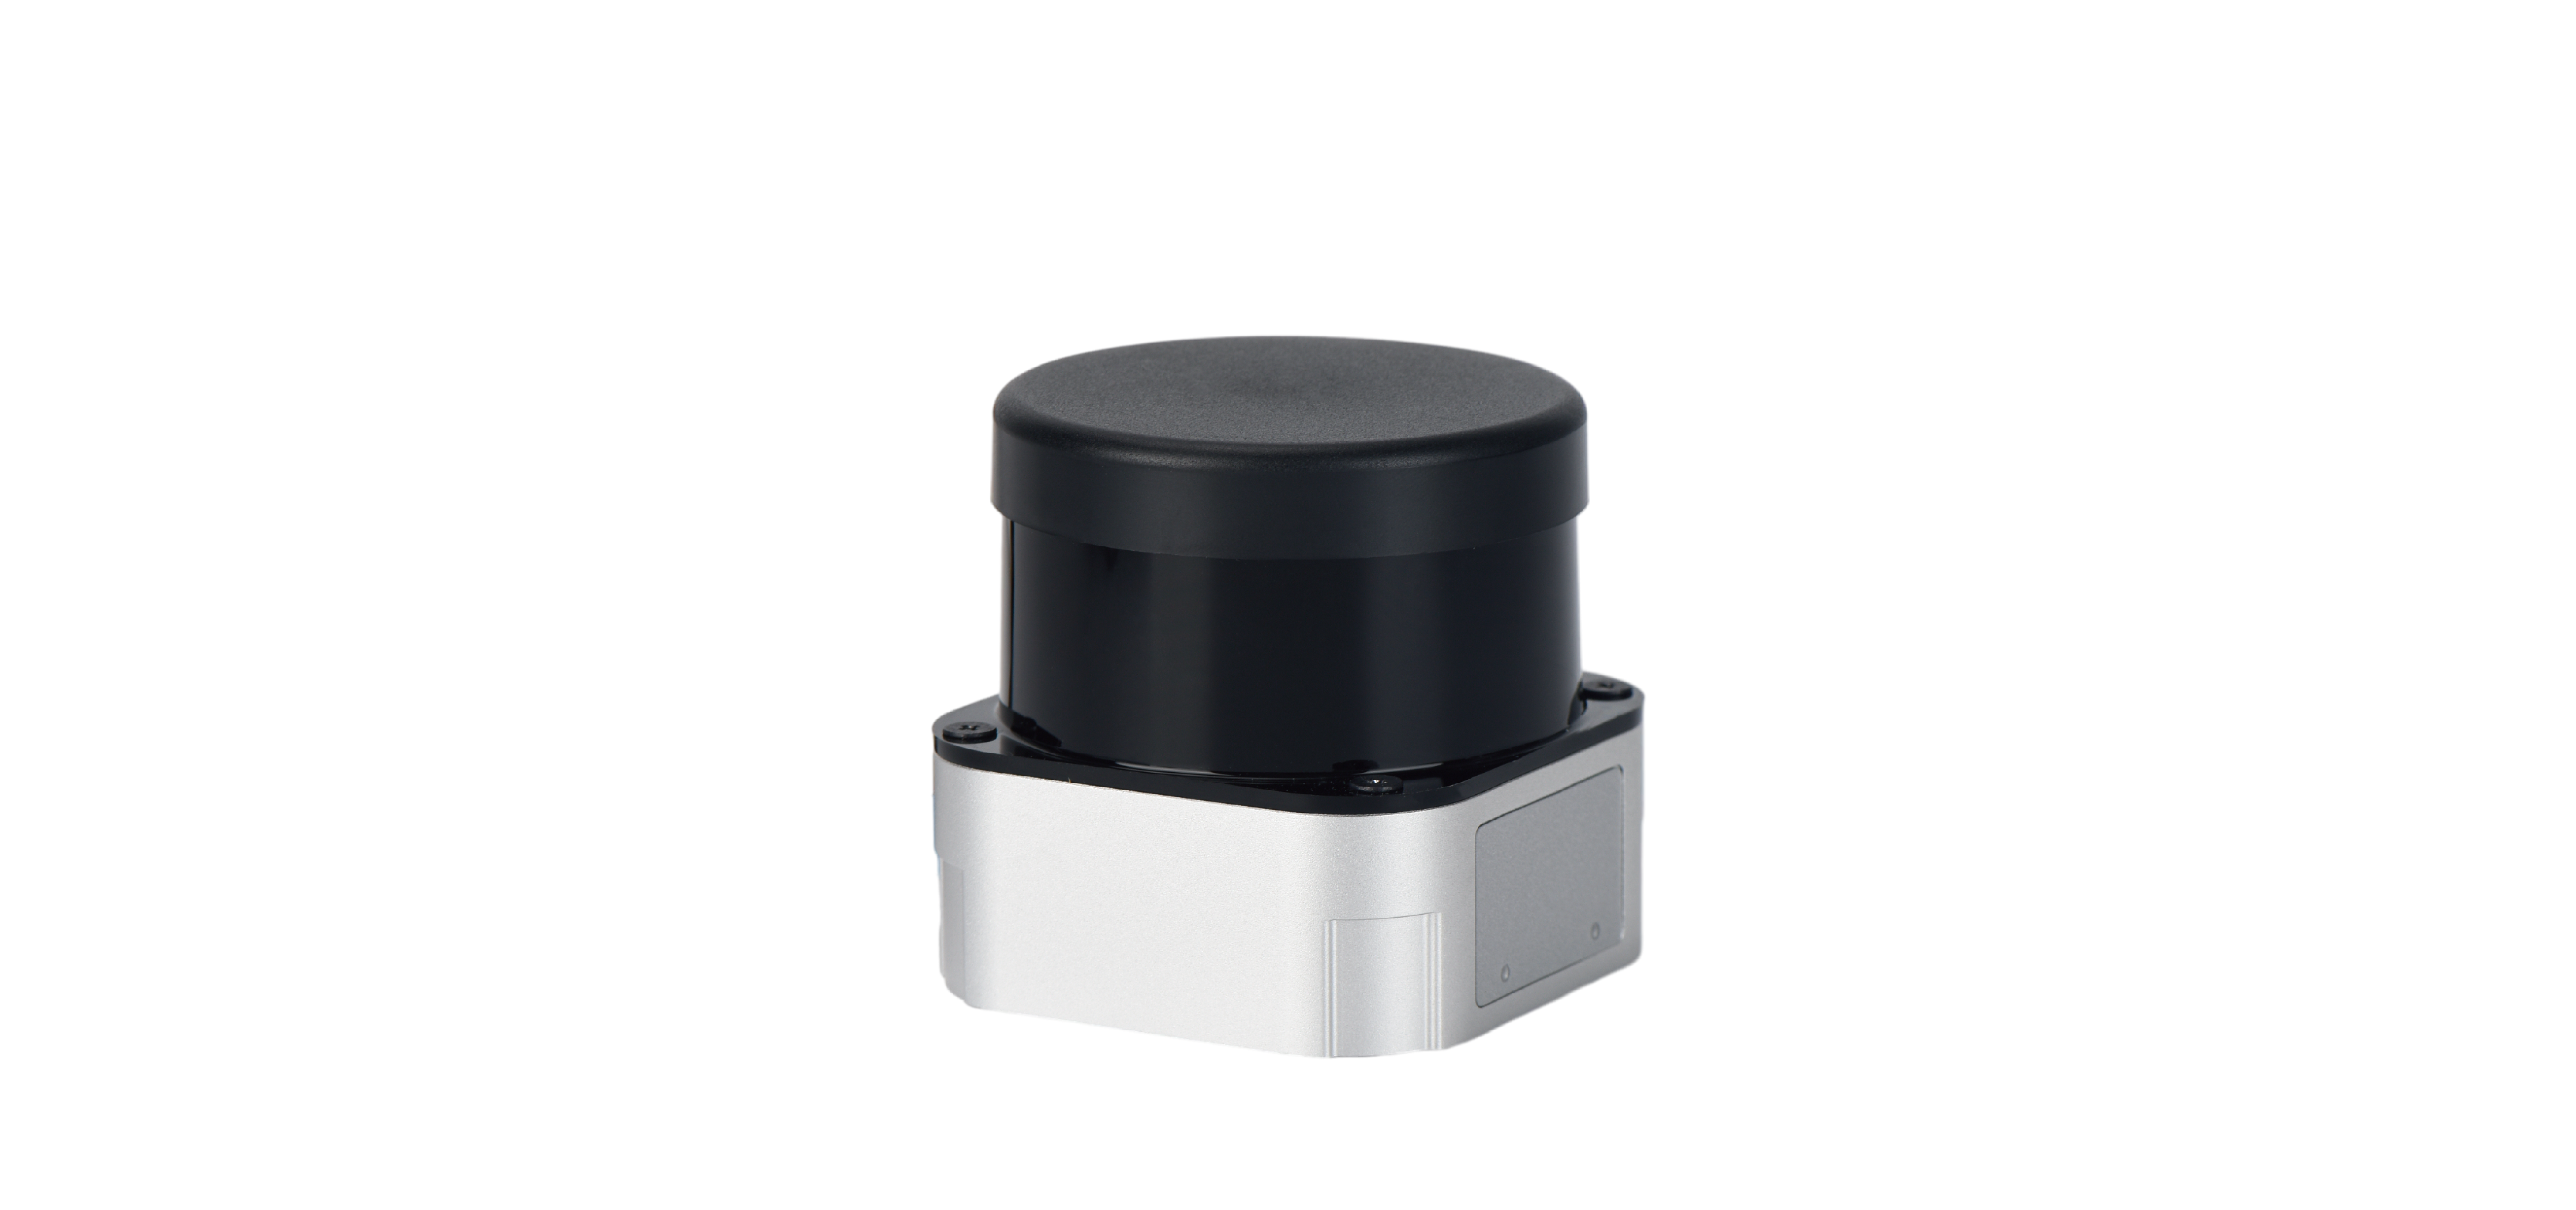
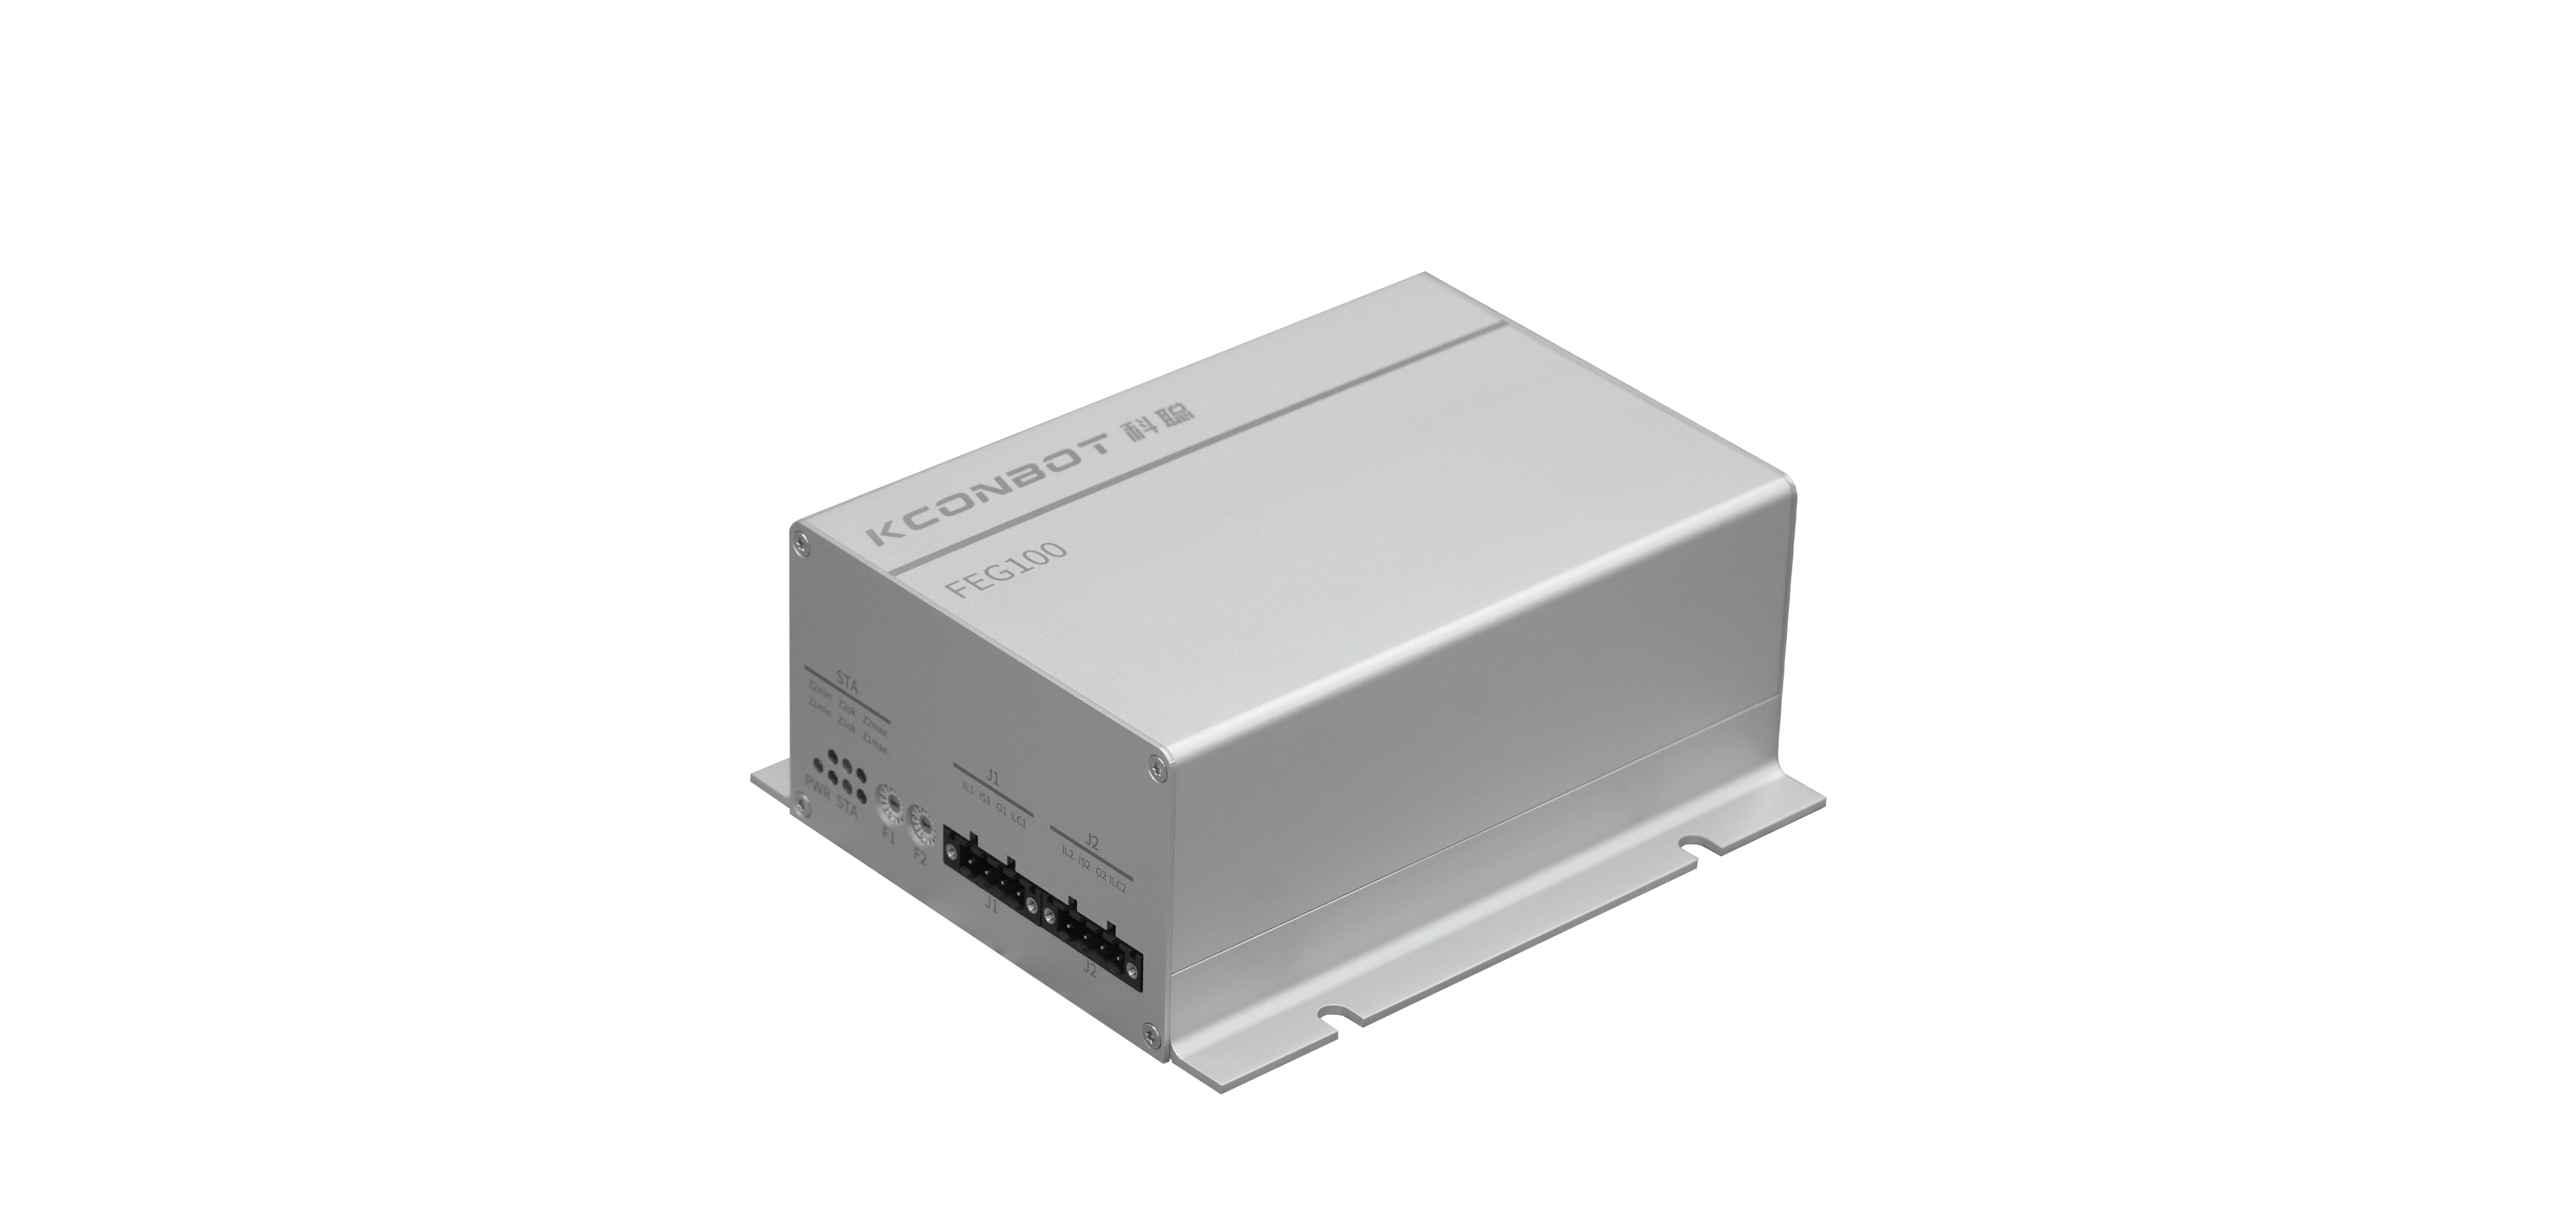
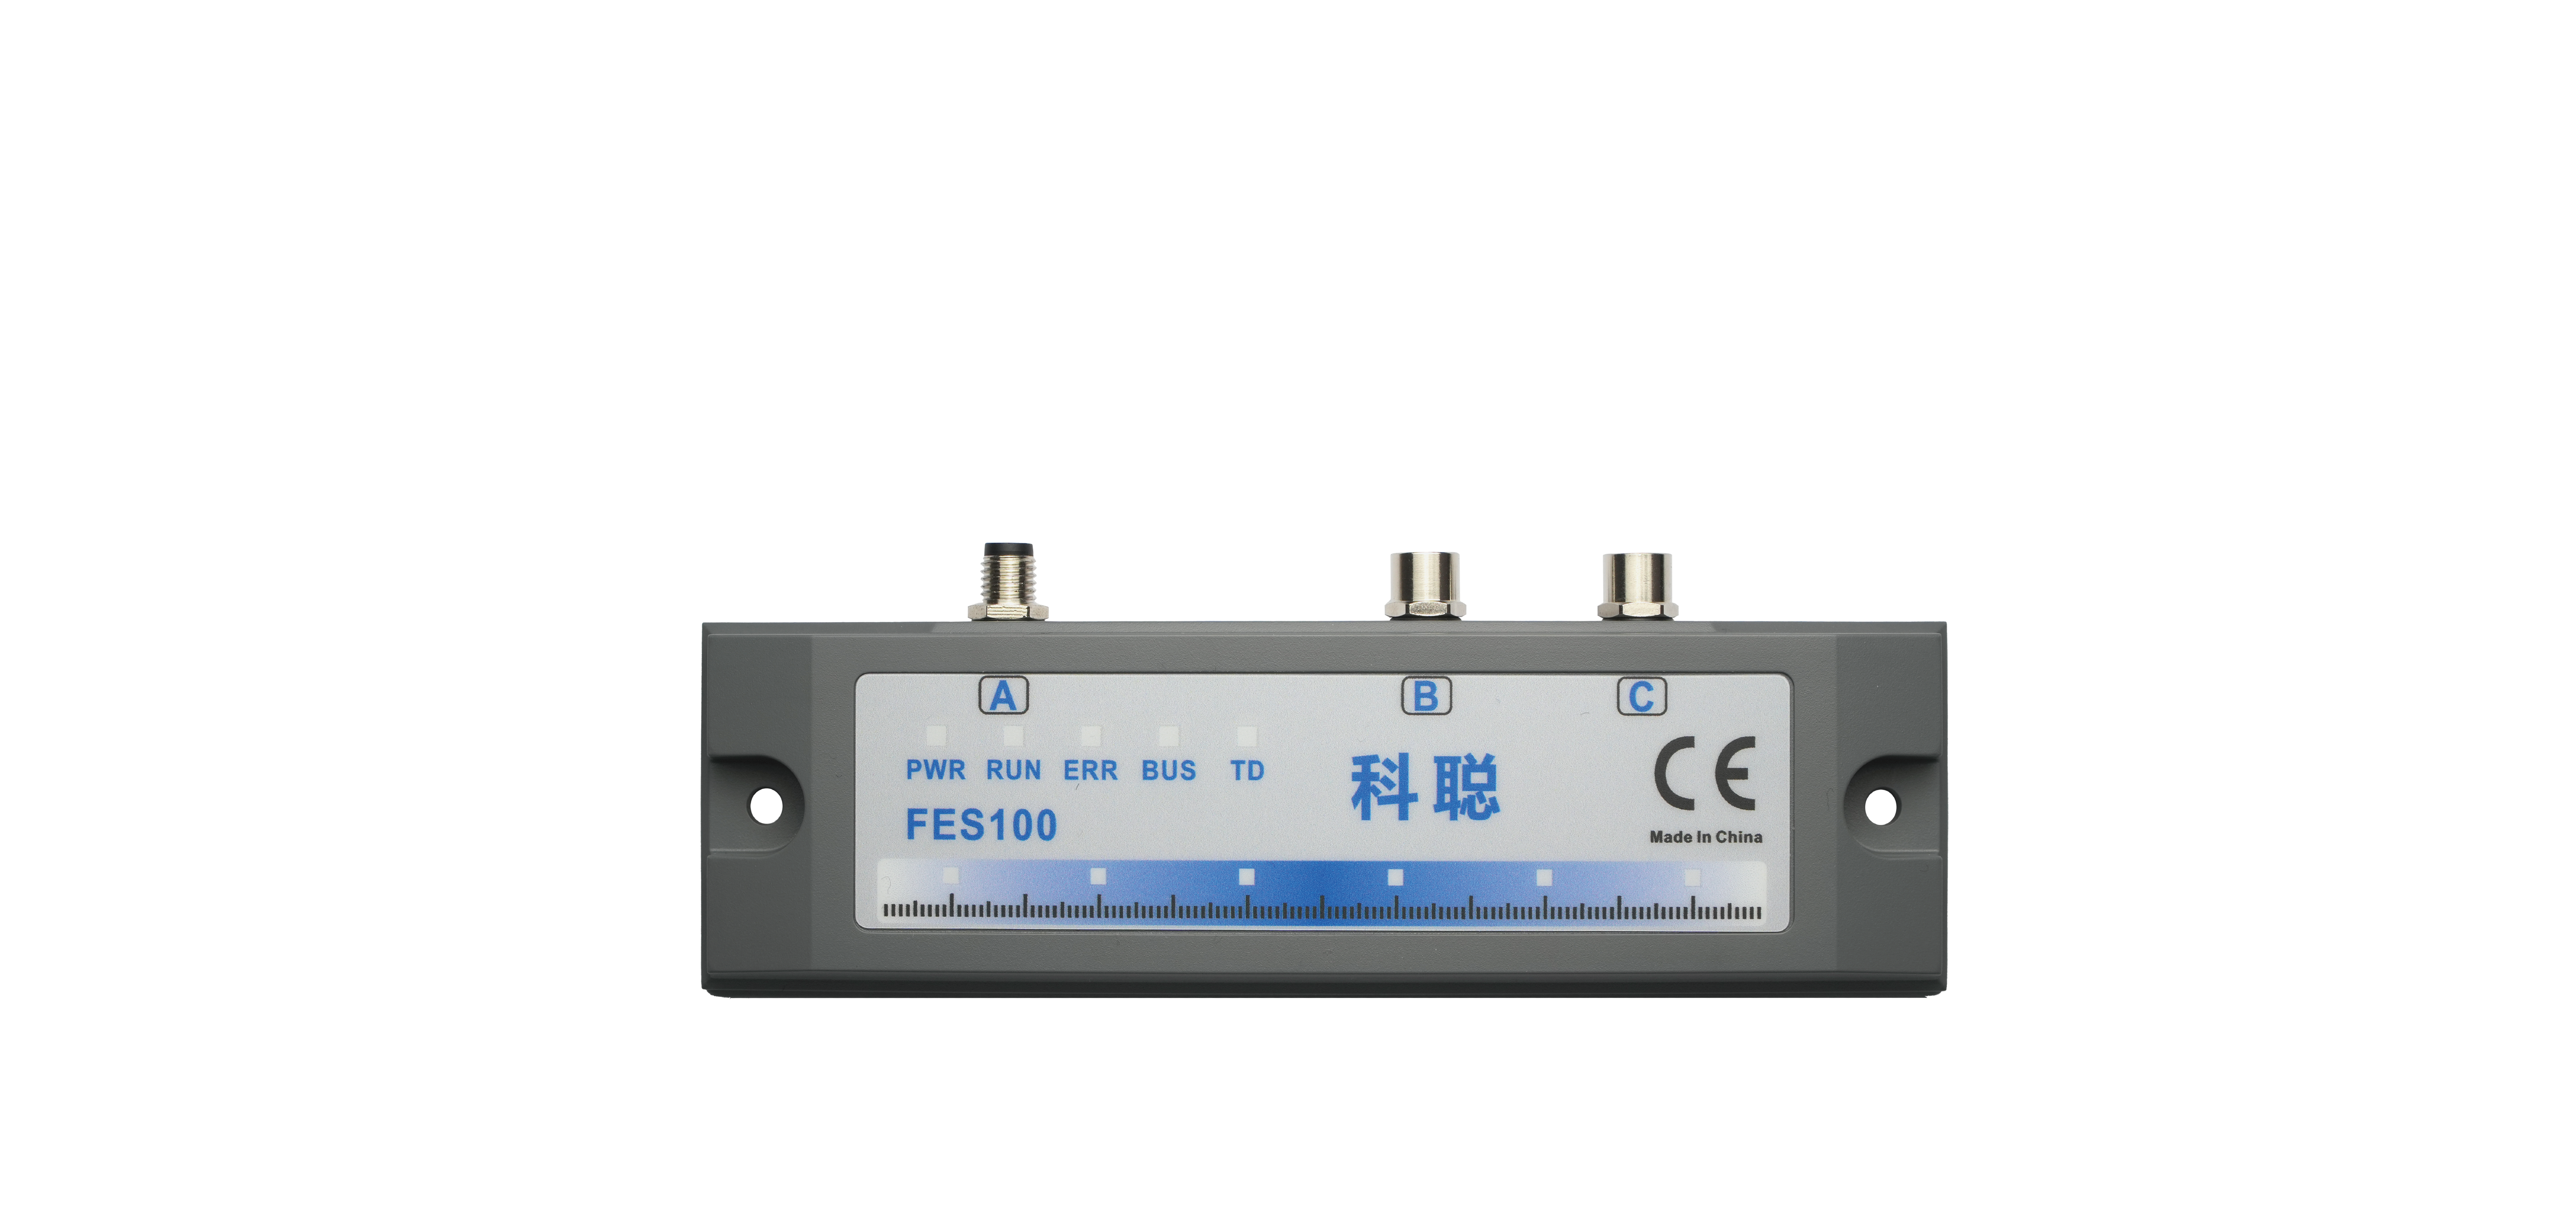
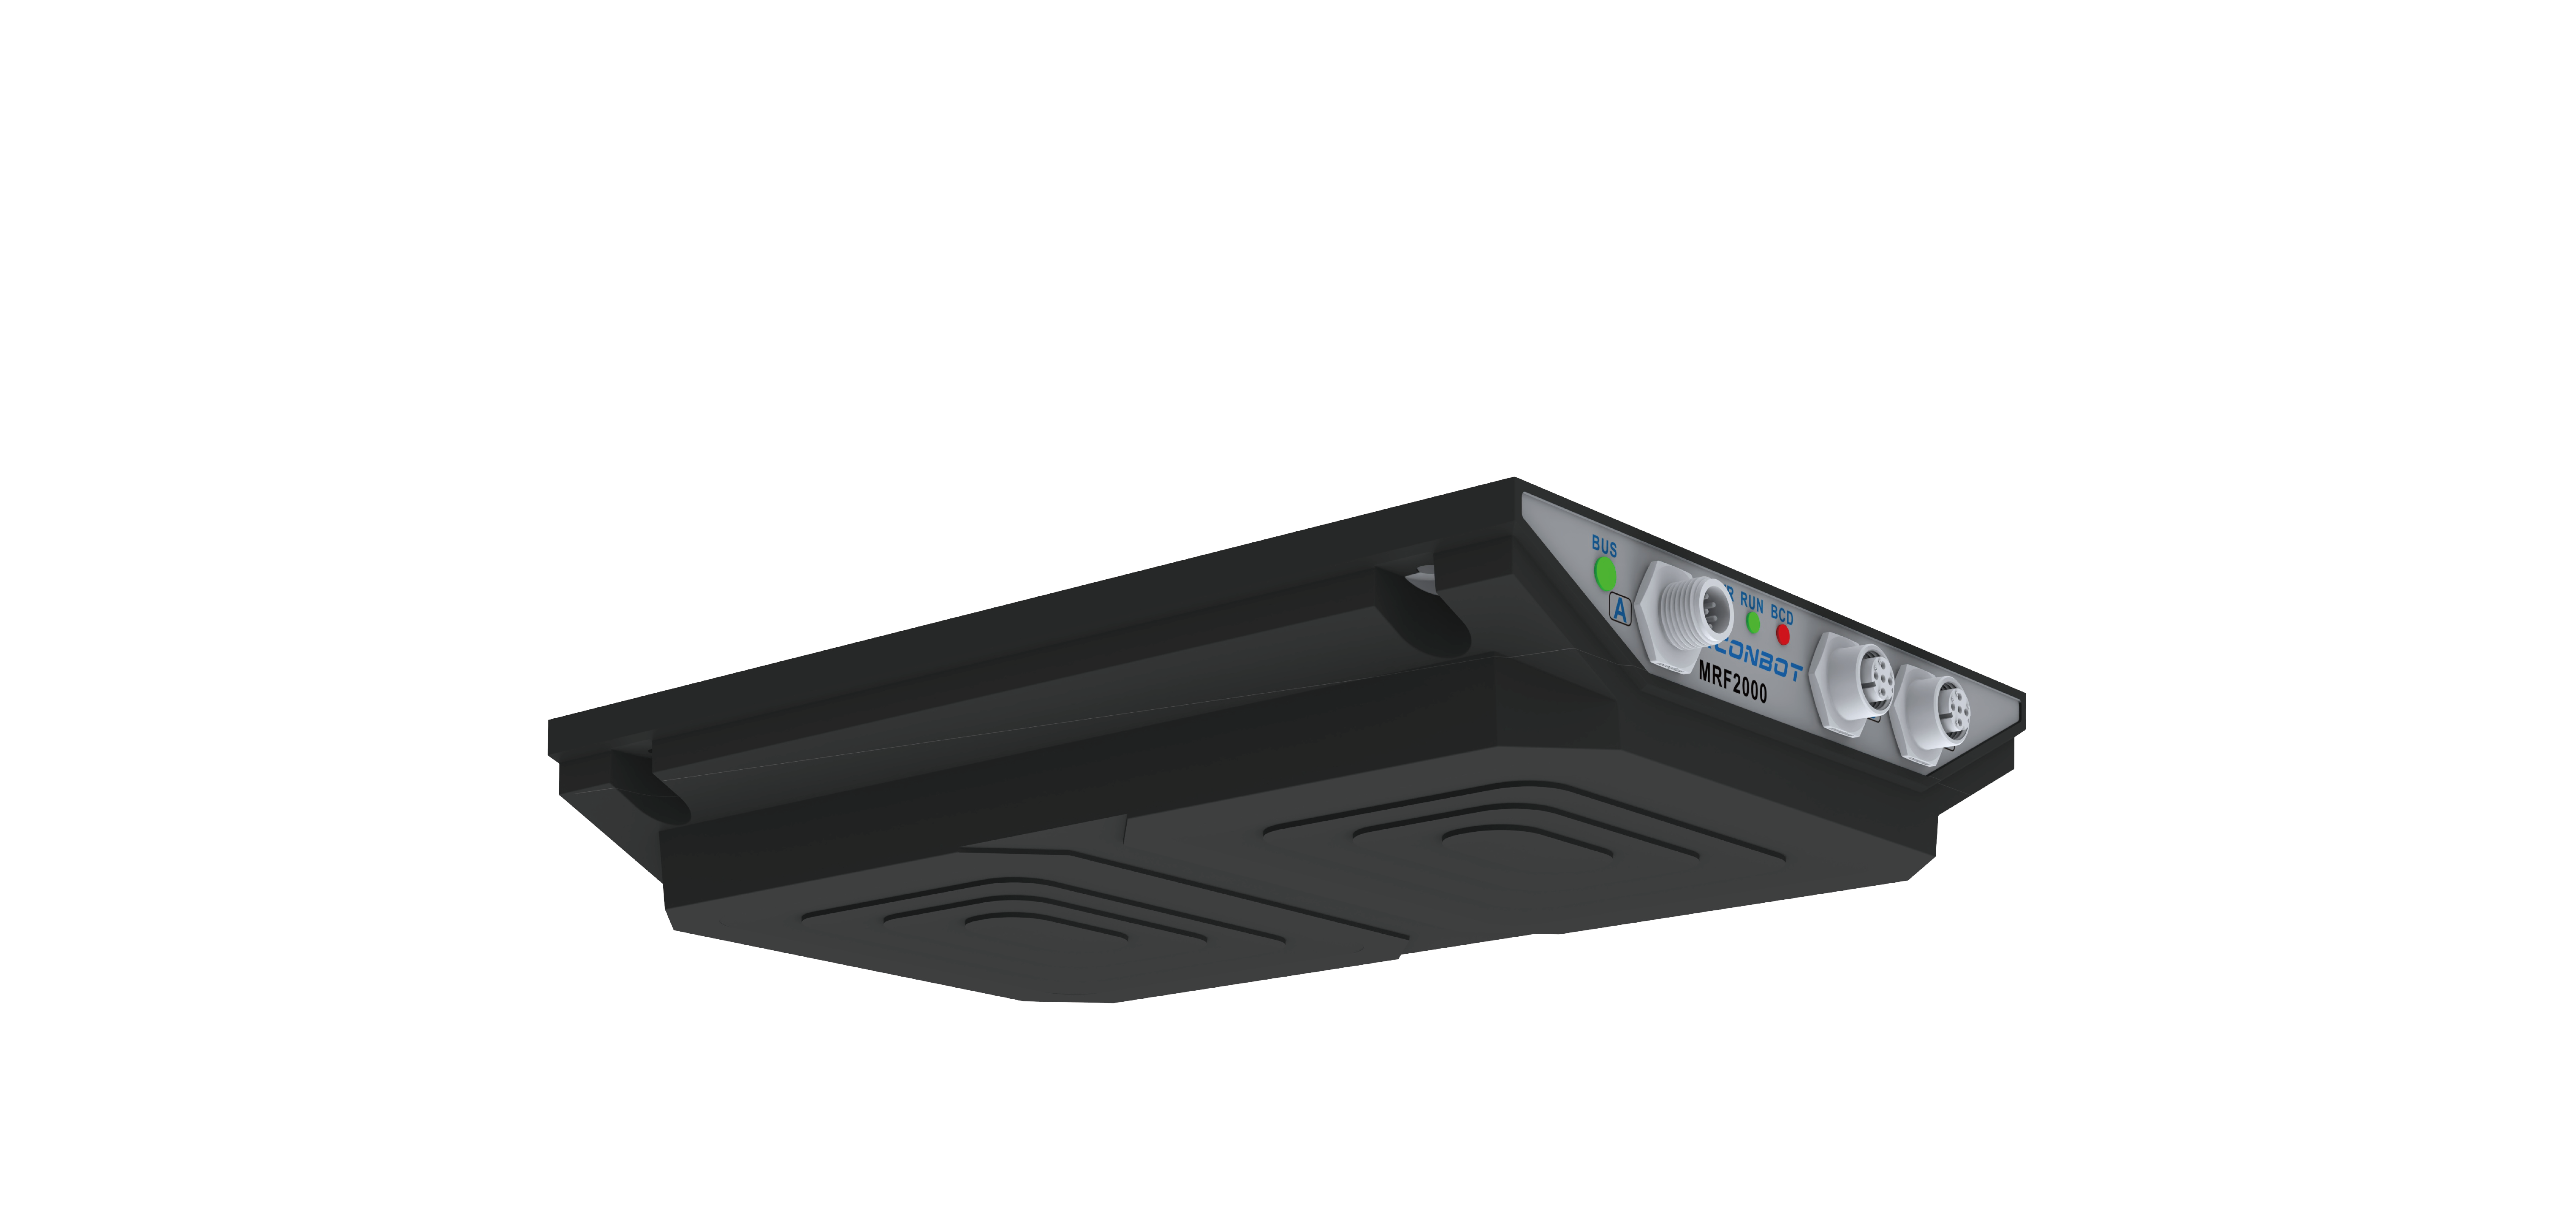
The overall solution of fork-type handling mobile robot is mainly divided into nine modules according to the whole vehicle function of the mobile robot, such as control system, navigation and sensing, chassis drive, actuator, safety detection, interaction module, communication module, power supply unit, and optional functions.